Robot Wiki
Citation-first encyclopedia of modern robot learning.
Contents
Manipulation & Learned PoliciesFrom imitation to VLA models
- Behavior Cloning Foundations
- Action Chunking (ACT and ALOHA)
- Diffusion Policy
- Vision-Language-Action Models
- The Pi Line
- Other Generalist Policies
- Comparison Matrix
- Hierarchical Approaches
- RL Fine-Tuning of Policies
- Real-Time Execution
- Cross-Embodiment Transfer
- Knowledge Insulation
- Robot Learning Curriculum for ML Engineers
- Action Spaces for Robot Learning
- Foundation Models for Robotics
RL, Sim-to-Real & LocomotionPolicies trained in simulation
World ModelsLearned predictive simulators
Data, Hardware & EvaluationDatasets, robots and benchmarks
Classical FoundationsKinematics to state estimation
Frontier & Open ProblemsWhat still blocks deployment
Adjacent DomainsVehicles, drones, surgery and space
Featured article
A model that lets a robot imagine what its actions will do before it moves.
Featured scene
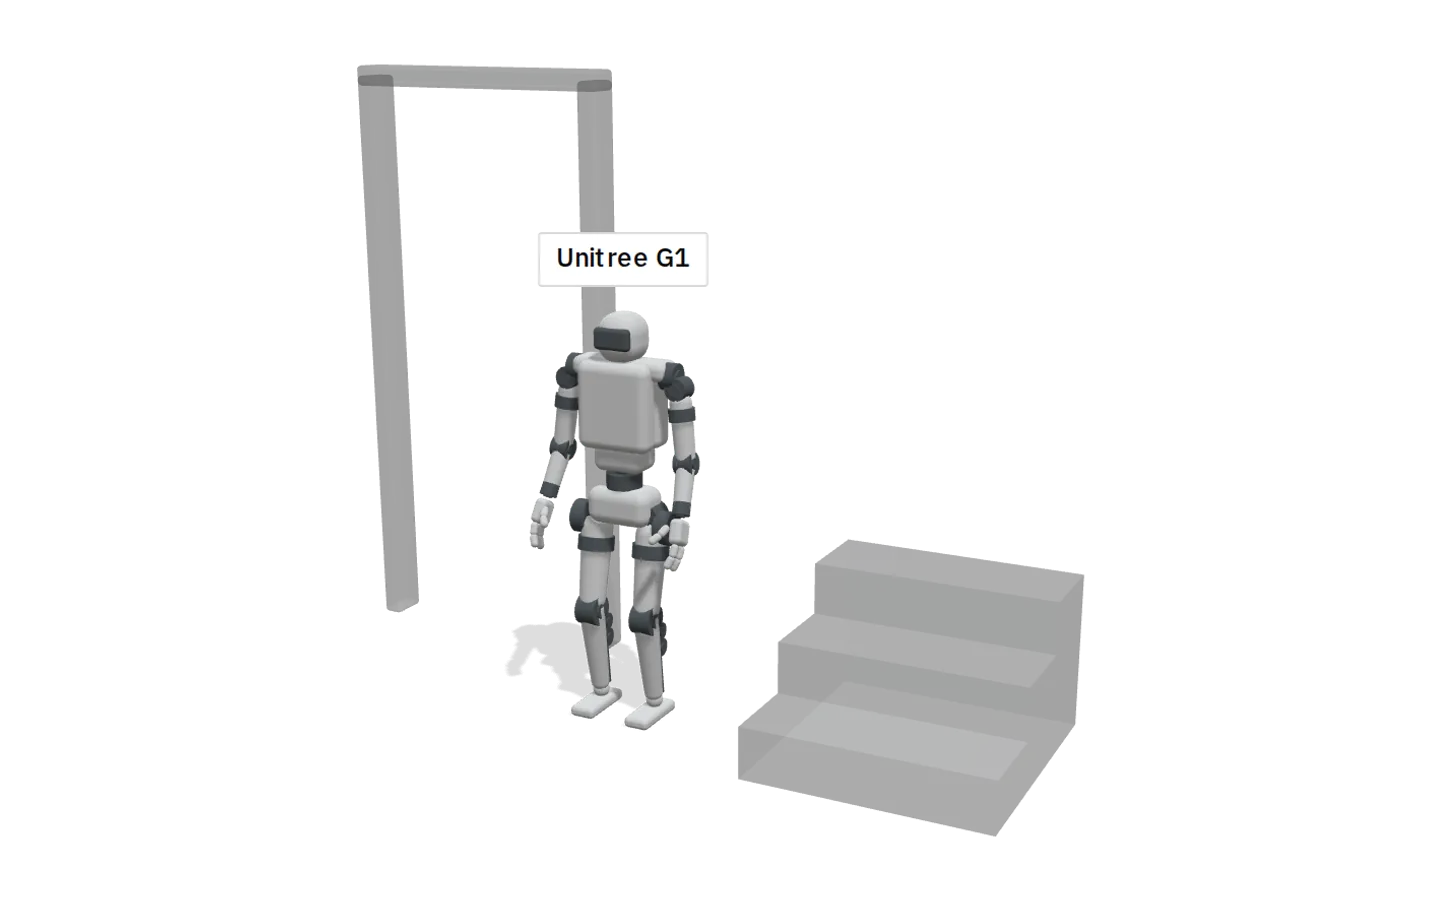
Of a Unitree G1's 23 motors, 12 move its legs and keep it balanced.
Loading…
A humanoid is shaped like us so it can use our doors, stairs and tools.
Did you know
- An ANYmal quadruped learned to walk on flat ground in under four minutes on one GPU Rudin et al. 2021Learning to Walk in Minutes Using Massively Parallel Deep Reinforcement Learning. Nikita Rudin, David Hoeller, Philipp Reist et al., CoRL 2021..
- ACT learned six bimanual tasks, each from about 10 minutes of demonstrations Zhao et al. 2023Learning Fine-Grained Bimanual Manipulation with Low-Cost Hardware. Tony Z. Zhao, Vikash Kumar, Sergey Levine et al., RSS 2023..
- By 1961, Heinrich Ernst had a computer-controlled arm and hand stacking blocks at MIT Brooks 2025Why Today's Humanoids Won't Learn Dexterity. Rodney Brooks, 2025..