Dexterity
Contact-rich manipulation, touch sensing, in-hand reorientation and deformables.
Dexterity is skilled contact-rich manipulation, such as reorienting an object in the hand or folding cloth. It remains unsolved: a model Physical Intelligence fine-tuned on Benjie Holson's Humanoid Olympics tasks averaged 52% success on themSource 21.
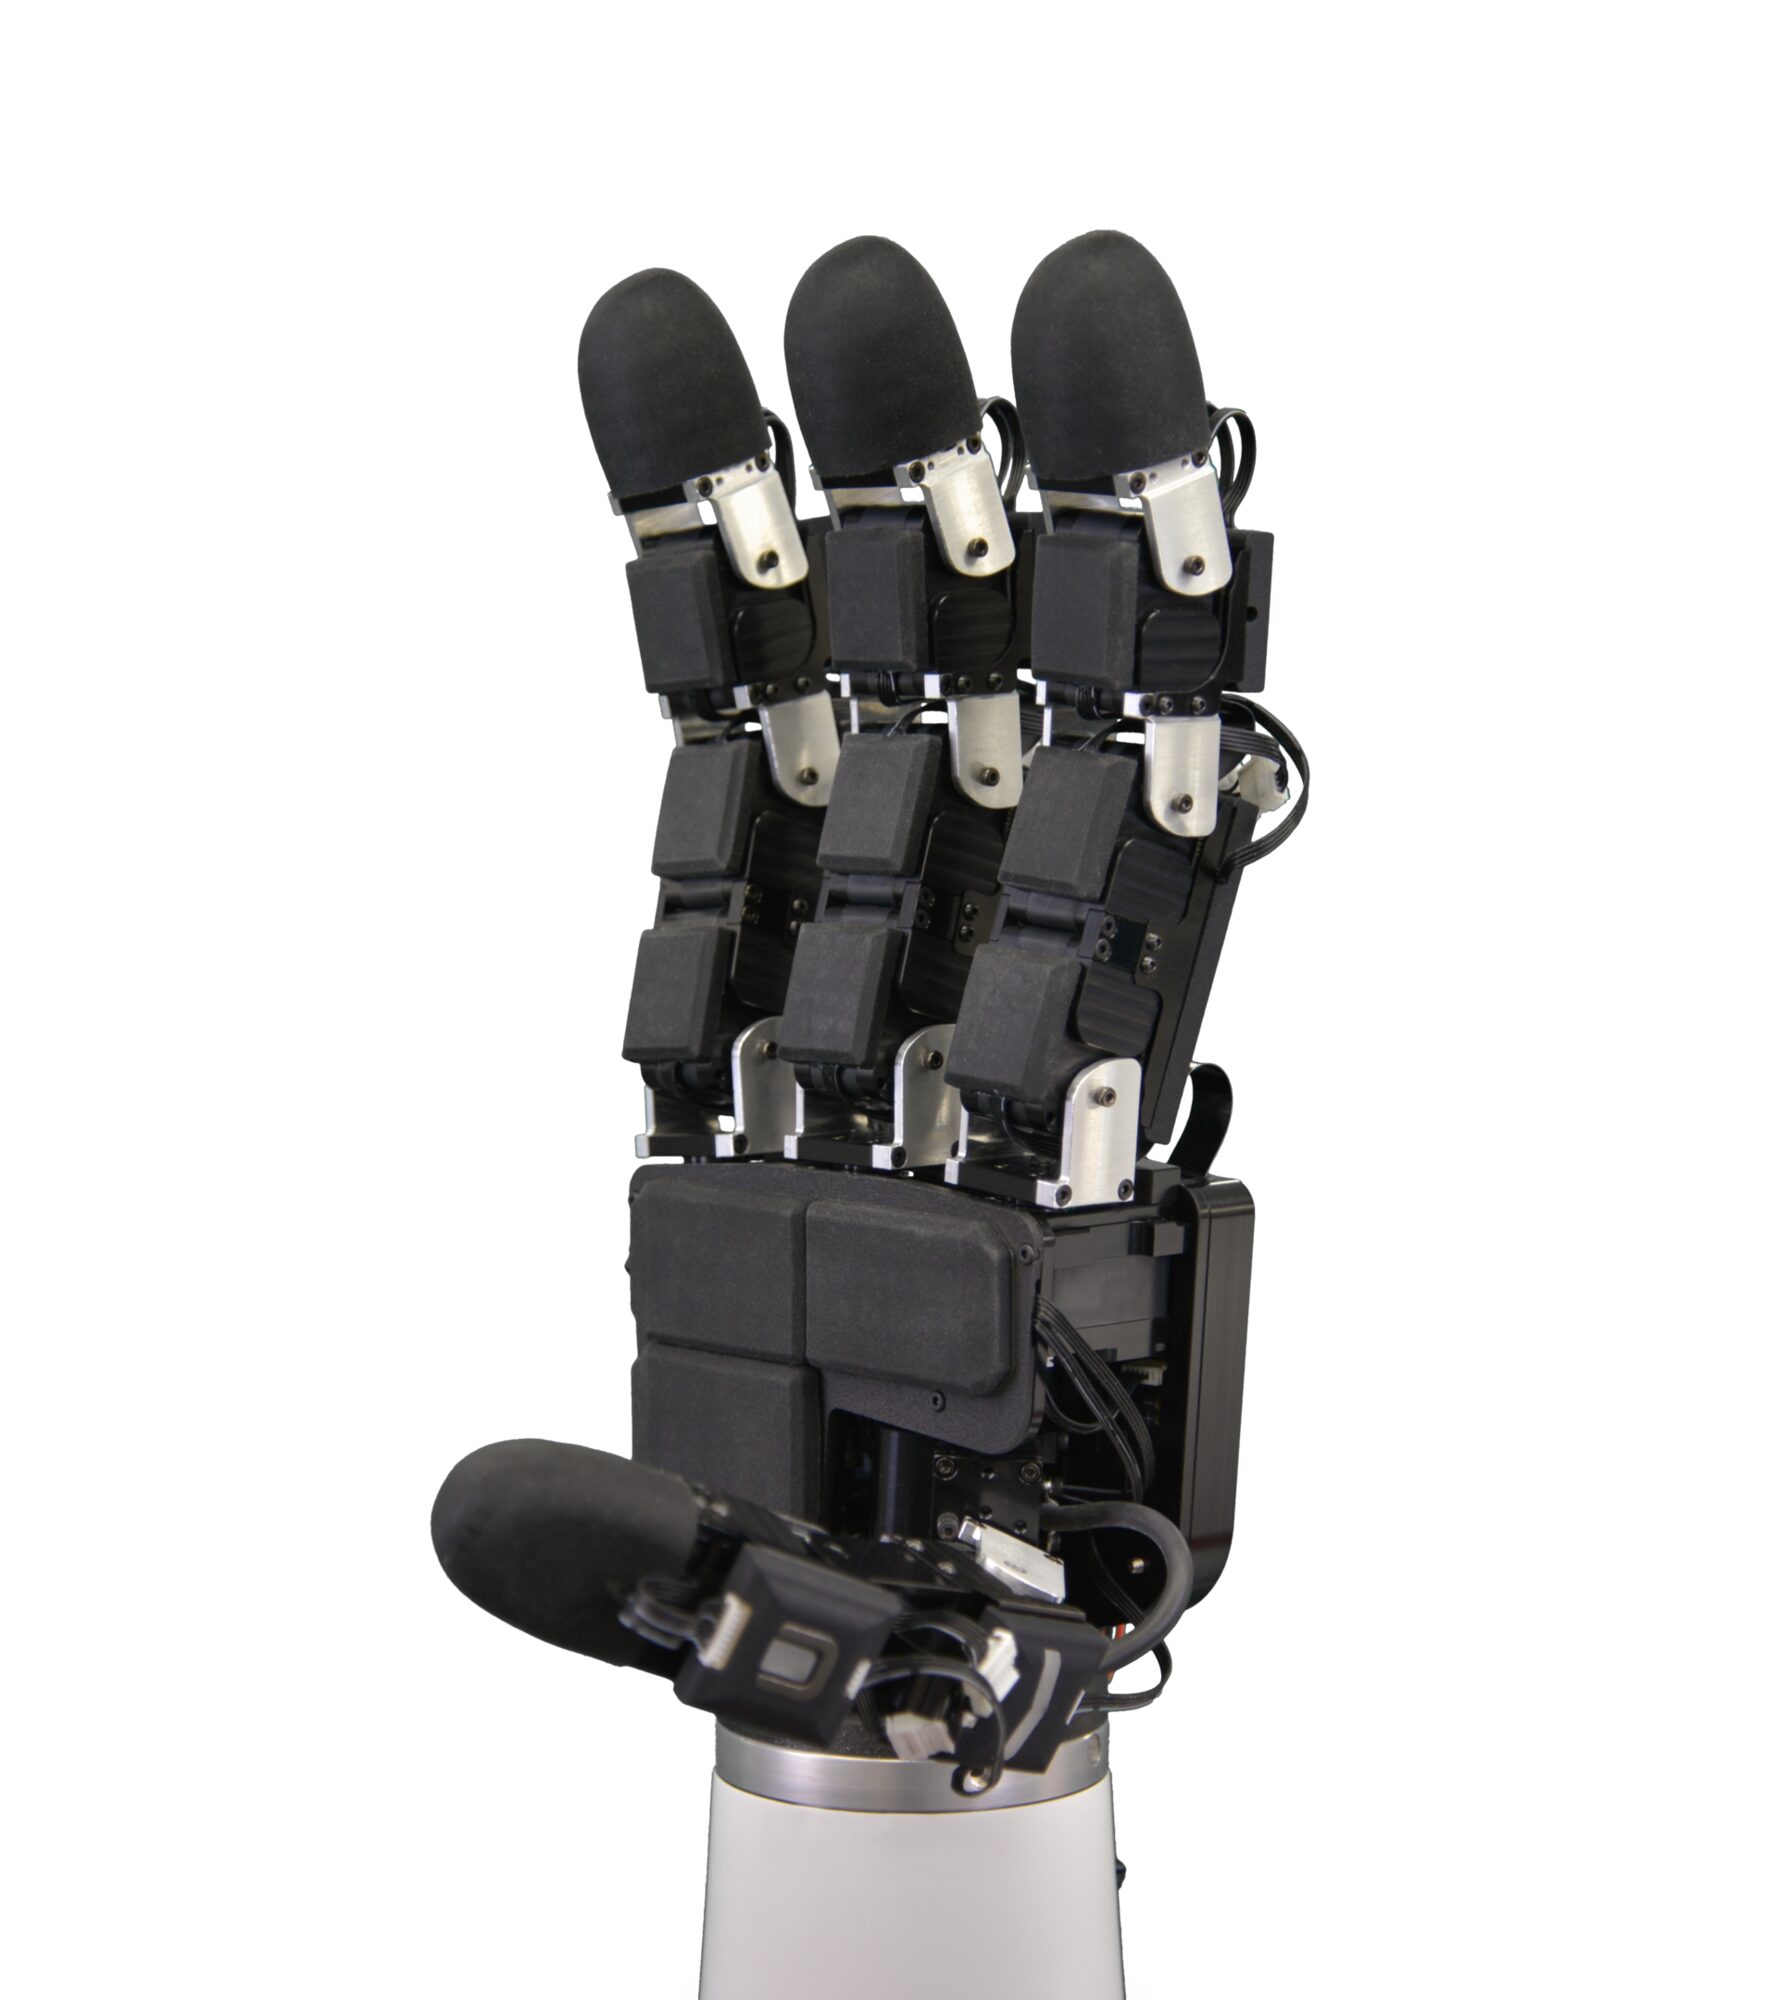
Rodney Brooks opens his dexterity essay with Heinrich Ernst's PhD work: by 1961, he writes, Ernst had connected a computer-controlled arm and hand to MIT's TX-0 and had it picking up and stacking blocksSource 1. Hands are hard because of contact: grip force, slip and contact geometry decide success, and cameras lose most of that state once the fingers close. Impedance control governs a contact where position or force commands alone cannot, and touch lets a controller observe the contact it shapes.
The five 2026 hands below rank differently by touch and by price. Figure says each Figure 03 fingertip can detect three grams of pressureSource 7, and Shadow priced its hand at €110,000 including support in 2022Source 13.
Dexterous hands
No hand here publishes both touch sensitivity and price
Sort by
Adjust more
Compare hands
Select hands to compare their trade-offs.
Grey means the maker hasn’t published it. No hand shows both.
- Phoenix handSanctuary AI
- Ways it can move
- 21
- Lightest touch felt
- about half a gram
- Price of the hand
- not disclosed
- Figure 02/03Figure AI
- Ways it can move
- 16
- Lightest touch felt
- 3 grams
- Price of the hand
- not disclosed
- Optimus Gen 3Tesla
- Ways it can move
- 22
- Lightest touch felt
- not disclosed
- Price of the hand
- not disclosed
- Dexterous HandShadow Robot
- Ways it can move
- 20
- Lightest touch felt
- not disclosed
- Price of the hand
- €110,000
- H2 (Dex5-1 option)Unitree
- Ways it can move
- 20 (16 active)
- Lightest touch felt
- not disclosed
- Price of the hand
- not disclosedWhole robot: $29,900
5 hands, lightest touch felt first
How this was made
“Ways it can move” is the hand’s degrees of freedom (DoF), the number of independently driven motions. “Lightest touch felt” is the tactile threshold, the smallest force a fingertip sensor registers: Sanctuary reports about 5 mN for the Phoenix fingerpads (about 0.5 gram-force), Figure reports 3 g (about 29 mN) for its fingertips. Every other value is one the maker has not published, shown as not disclosed; no number is guessed.
Unitree’s $29,900 is the list price of the whole H2 robot; the base model ships with placeholder hands and the five-finger Dex5-1 hand is a paid option with no published price, so the card shows the hand price as not disclosed and the “Lowest price” order leaves the whole robot out. Shadow’s €110,000 is its 2022 price including support.
| Hand | DoF | Tactile threshold | Cost | Training bet | Source |
|---|---|---|---|---|---|
| Phoenix handSanctuary AI · Hydraulic, miniaturized valves | 21 | approx. 5 mN | not disclosed | Tactile + RL | RoboZapsSanctuary AIJul 2026 |
| Figure 02/03Figure AI · Actuation not disclosed | 16 | 3 g≈29 mN | not disclosed | Vision + tactile | Figure AIFigure 02 releaseJan 2026 |
| Optimus Gen 3Tesla · Tendon-driven electric, motors in the forearm | 22 | not disclosed | not disclosed | Vision-only | DROIDSTeslaratiApr 2026 |
| Dexterous HandShadow Robot · Tendon-driven electric, 20 DC motors, 24 joints | 20 | not disclosed | €110,0002022 | Research platform | Shadow RobotShadow cost blogDec 2022 |
| H2 (Dex5-1 option)Unitree · Electric | 20 (16 active) | not disclosed | $29,900whole robot | Not disclosed | RoboZapsUnitreeJul 2026 |
17,000
hand receptors
low-threshold mechanoreceptors, ~1,000 per fingertip
7 s
match lighting (Brooks)
his reported first-video time; second described as four times as long
5 mN
best threshold
Sanctuary's array; a human fingertip feels ~3 mN
€110k
research hand
Shadow Hand Plus, 2022, support included
The tactile gap
Tactile sensing
Fingertips can feel a slip the camera can’t see
Adjust more
glassrobot fingers, with the camera aimed at onefingertip sensor
beat 4 / 4 Slip 3 mm · felt at the fingertips · grip raised from 4 to 6 newtons
schematic
When fingers hide an object from the camera, touch sensors can still notice it slipping and trigger a firmer grip.
How this was made
A schematic of contact feedback, drawn to show where the information is: not a sensor measurement, not a demonstrated recovery rate and not a dexterity claim for any hand. Source-scoped hardware claims, such as fingertip thresholds, are in the hand cards above and their table under "How this was made".
The drawing is a slip test stand. A parallel gripper hangs from a column and holds a glass between two rubber fingertip pads, each with a grid of touch cells on its face. A camera on a post looks along the line the fingers close on, so all it sees is the back of the near finger. A dial indicator rests its plunger on the rim and reads how far the glass slides, one turn for 5 mm; the dial on the gripper reads how hard each pad presses.
The numbers are authored for the schematic. Two pads hold a glass by friction as long as twice the friction coefficient (0.4) times the grip is at least the glass's load. A 2.94 newton glass held at 4 newtons a pad gets 3.2 newtons of friction, just enough. An extra 0.8 newtons, as if the glass were knocked or topped up, is more than the grip can hold, so the glass slides. The grip rises to 6 newtons, and the glass stops where the friction passes the load, at 4.68 newtons a pad, 3 mm lower.
The four steps, in order:
- A robot hand holds a glass; from where the camera sits, the fingers hide where they touch the object.
- The glass slips between the fingers, and the camera cannot see it happen.
- The fingertip sensors feel the glass sliding and tell the hand to squeeze harder.
- When fingers hide an object from the camera, touch sensors can still notice it slipping and trigger a firmer grip.
Touch catches a slipping glass. Beat 1: A robot hand holds a glass; from where the camera sits, the fingers hide where they touch the object. Beat 2: The glass slips between the fingers, and the camera cannot see it happen. Beat 3: The fingertip sensors feel the glass sliding and tell the hand to squeeze harder. Beat 4: When fingers hide an object from the camera, touch sensors can still notice it slipping and trigger a firmer grip. A schematic of contact feedback, drawn to show where the information is: not a sensor measurement, not a demonstrated recovery rate and not a dexterity claim for any hand. Source-scoped hardware claims, such as fingertip thresholds, are in the hand cards above and their table under "How this was made".
A review of Roland Johansson's work reports about 17,000 low-threshold mechanoreceptors in the hand's glabrous skin, roughly 1,000 of them at each fingertipSource 2. Brooks cites two videos from Johansson's lab. In his account, lighting a match took seven seconds, then four times as long once the same person's fingertips were anesthetized, with difficulty picking up and orienting the match. He says she could still sense other things in the rest of her fingers and hand and all the forces she ordinarily felt with her skeletal muscle systemSource 1.
In his September 8, 2025 post, Benjie Holson described limitations of the learning-from-demonstration setups he was seeing, explicitly calling them a general trend with exceptions. He pointed to the lack of good standard ways to relay wrist-force information to the human teleoperator, difficulty controlling fingers beyond open and close, and the difficulty of making human-like touch sensing available to the puppeteer. His estimate of about 1 to 3 cm of task precision was a guess from videos. He said it was likely more a teleoperation limitation than a model limitation and pointed to a video he described as showing sub-centimeter tasksSource 3.
Luo and colleagues define tactile robotics as developing and integrating tactile-sensing technologies into robotic systems. Their 2025 outlook discusses challenges across sensor materials, networks, simulation, benchmarking, data interpretation, multimodal learning, and active touchSource 19. When he wrote the essay, Brooks concluded: "It looks like humanoid robots will need a sense of touch, and a level of touch sensing that no one has yet built in the lab" for tasks such as the match demonstrationSource 1.
The bet against touch
Brooks frames the scaling counterargument as an imagined inner dialogue: end-to-end learning succeeded in speech-to-text, image labeling, and language models, so collecting examples of human hand use might yield dexterous control. He replies that those successes depended on engineered inputs and that dexterity learning will likely require the right sensory data and the right thing to learnSource 1.
Brooks reproduces an eWeek report that describes Tesla as moving Optimus training toward a "vision-only approach" instead of motion capture suits and teleoperation. The quoted report says workers wear helmet-and-backpack rigs with five in-house cameras, record tasks such as folding a t-shirt or picking up an object, and use the videos to train Optimus to mimic those actionsSource 1.
Figure's September 2025 Project Go-Big announcement describes a pretraining data-collection initiative; it reports no general-dexterity result. Its initial human-video result is navigation. Helix, trained on 100% egocentric human video with no robot demonstrations for that approach, maps images and language to low-level SE(2) velocity commands, a transfer Figure calls zero-shot and, "to our knowledge", a first. Collection in Brookfield's residential environments had begun and would expand; the announcement's more than 100,000 residential units describe Brookfield's portfolio, without stating that those units were homes or trajectories collectedSource 4.
In October 2026, Haonan Chen, Edward Adelson, Jiajun Wu, Robert Howe, Yilun Du and colleagues at Harvard, MIT, the University of Pennsylvania and Stanford trained a camera-based estimator that reads grip force from how a compliant Fin Ray gripper bends. On three held-out episodes the mean error was 0.91 N, against 4.20 N from motor current. Their Diffusion Policy also outputs force, samples 32 actions per step and keeps the one closest to a target force from the demonstrations. On an ARX arm with no force or tactile sensor, over 15 trials per task, this raised success over a single sample from 46.7% to 86.7% for grasping an empty soda can, 0% to 73.3% for berry picking, 6.7% to 46.7% for in-hand reorientation and 26.7% to 73.3% for plug insertionSource 31.
The bet on touch
Jeremy Fishel, principal researcher at Sanctuary AI, counters that with video alone you do not know you have touched something until well after the collision has physically moved the objectSource 8. Sanctuary's CEO James Wells calls touch a key enabler for creating human-level dexterity in robotsSource 8. The company's hydraulic Phoenix hands carry fingerpad arrays of micro-barometer cells sensitive to about five millinewtons, against roughly three for a human fingertipSource 11.
Figure's October 2025 announcement describes a palm camera in each Figure 03 hand. It says each fingertip sensor can detect "three grams of pressure", comparing the sensitivity to a paperclip's weightSource 7. Its January 2026 Helix 02 announcement lists head cameras, palm cameras, fingertip tactile sensors, and full-body proprioception as System 1 inputs. Figure describes this as "the first time we've demonstrated neural network policies that depend on these modalities"Source 6.
Touch now ships on flagship hands, Figure's included, and tactile foundation models exist, but no tactile training pipeline yet runs at vision scale. Sparsh-X pretrained on about a million contact-rich interactions from Meta's Digit 360 sensor and lifted policy success rates by 63% over an end-to-end model using tactile imagesSource 17. TouchWorld couples a tactile world model with a fast tactile refinement policy to reach 65% success on six long-horizon contact-rich tasks, 15.7 points over the strongest baselineSource 18.
In June 2026, Dantong Niu, Yuke Zhu, Trevor Darrell and colleagues described T-Rex. It pairs a 100-hour tactile-rich dataset with a vision-language-action model that reads high-frequency touch through a variable-rate mixture-of-transformers and a temporal tactile encoder. On 12 tasks requiring delicate force control and deformable-object manipulation, its average success rate was more than 30% higher than the strongest baseline'sSource 24.
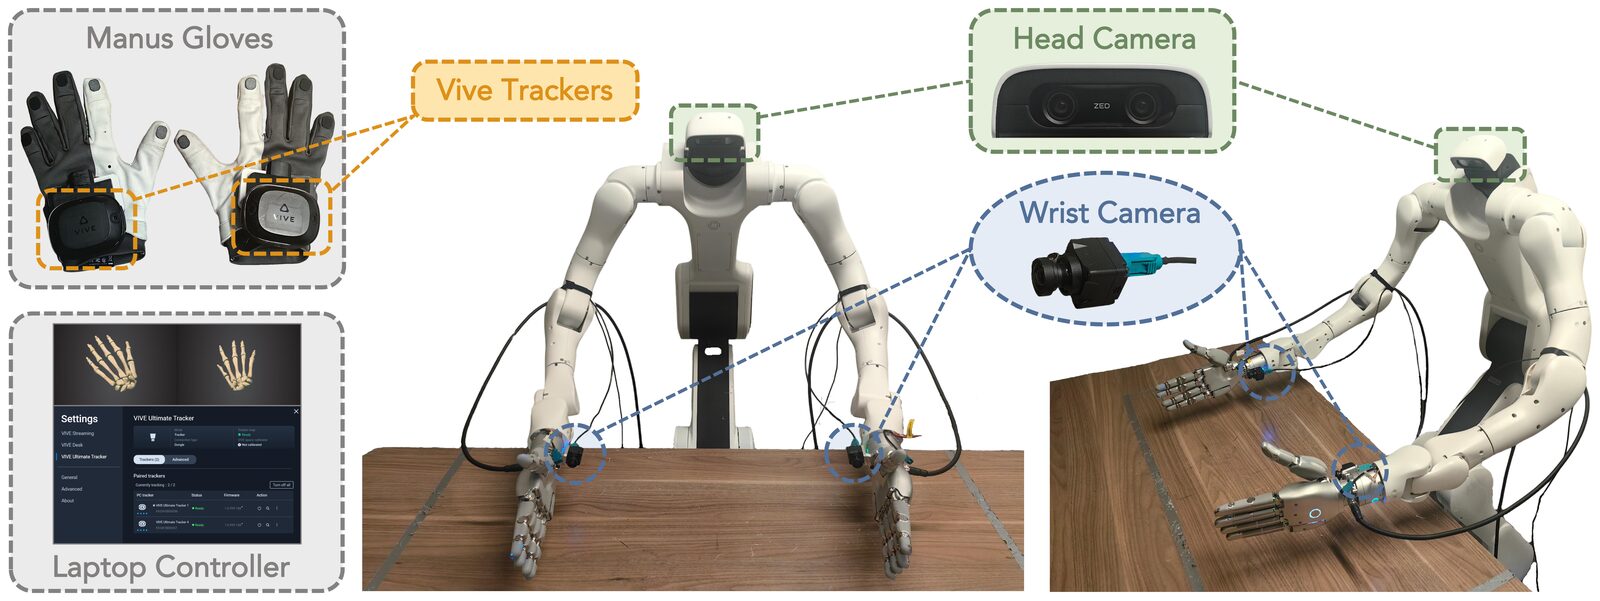
In September 2026, Enyi Wang and Yan Wang of Tsinghua University's Institute for AI Industry Research and colleagues reported TacDyn-WAM. This world action model predicts learned tactile representations instead of reconstructing tactile images. On five real-robot tasks with 60 demonstrations each, it averaged 71.0% success, 16 points above the tactile policy FTP-1. Pretraining on about 6,000 real visuo-tactile trajectories raised that to 85.0%Source 28.
Google's Gemini Robotics 2 drives the 22-DoF SharpaWave hand, itself a tactile designSource 20 Source 16. It reports 92% success unscrewing a light bulb but 32 to 44% on its other multi-finger tasks. DeepMind itself flags this spread as the hard remainderSource 20.
Five hands, five bets
Of the five hands compared above, Tesla's 22-degree-of-freedom tendon design has the most articulation and an admitted redesign behind it. Days after the V3 hand patents surfaced, Musk said of the design, "this one didn't actually work"Source 15 Source 14. Sanctuary's hydraulic hand pairs the most sensitive disclosed touch with a working in-hand demo, and its maker has since pivoted to selling softwareSource 11.
Shadow's Dexterous Hand, the two-decade research benchmark, runs more than 100 sensors at 1 kHzSource 12. Each finger has independent side-to-side motion for in-hand workSource 12, and the lab price is €110,000 including supportSource 13.
Unitree lists the entire H2 robot at $29,900, but the base model ships with non-functional placeholder hands. Its tactile option, the H2 Plus with Sharpa Wave hands, lists at $100,000Source 16. Figure's own release for Figure 02, dated August 6, 2024 and hosted by PRNewswire, describes the second-generation robot's "4th generation hands" as "equipped with 16 degrees of freedom". It does not say whether that count is per hand or combined, or give an actuator countSource 5.
Boston Dynamics announced a new Atlas hand on October 1, 2026. It has four fingers and 13 directly actuated degrees of freedom, up from seven, and pressure sensors across the fingertips and palmSource 29. It has no little finger, which would have needed three more actuators. It is built to be simulated accurately enough for training with reinforcement learningSource 29.
In September 2026, Amirhossein Kazemipour, Hehui Zheng and Robert Katzschmann of ETH Zurich's Soft Robotics Lab made a hand the whole robot. Their reinforcement-learning policies, trained in a simulator calibrated from hardware measurements, let an off-the-shelf 738 g WUJI hand with its own power and computer crawl on its fingers and work with them. On hardware it got back up from a fall in 21 of 25 trials and pressed the commanded arrow key for 29 of 32 consecutive commands while supporting its own weight. Guided by an overhead camera, it completed 15 cube deliveries to targets 10 to 40 cm away with a mean final error of 17 mmSource 32.
In-hand manipulation
In-hand manipulation, reorienting a held object without setting it down, separates a hand from a gripper. In the gold-medal "Use a key" event of Holson's Humanoid Olympics, a keyring with at least two keys and a keychain is dropped into the robot's waiting palm or gripper. Without putting the keys down, the robot must align, insert, and turn the correct key in a lockSource 3. The challenge rules do not report a completed robot run. Switch between the clamp and the hand in the figure below and try the same task with each.
Why are robot hands so hard?
Loading…
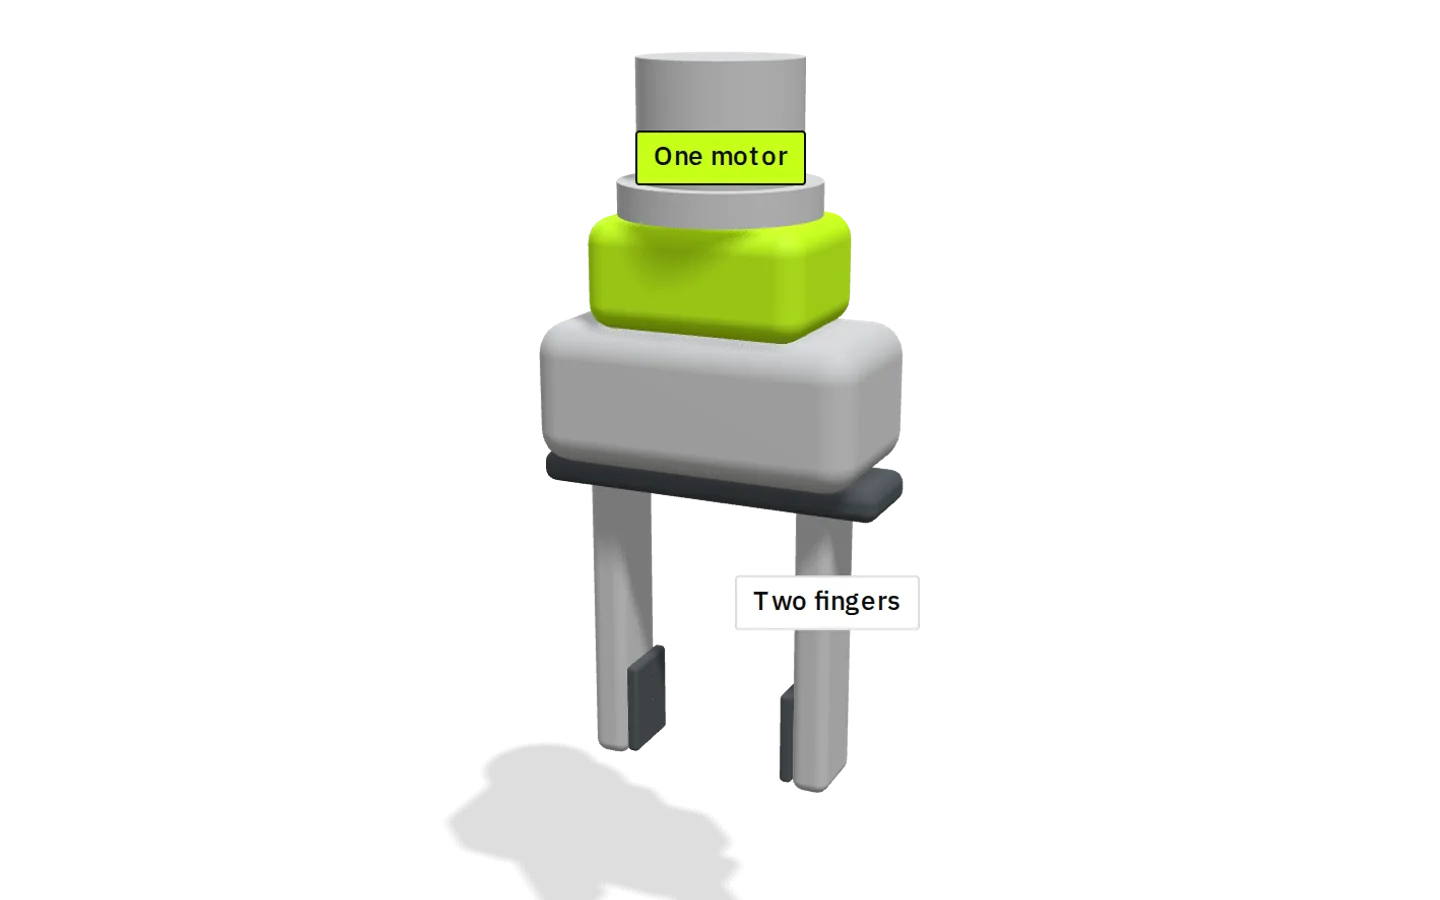
Most robots hold things with a simple clamp: two fingers and one motor. It can only open and close.
A hand moves in about 20 ways and feels touch, while most robots use a clamp that only opens and closes.
How this was made
The steps in words
- Most robots hold things with a simple clamp: two fingers and one motor. It can only open and close.
- Your hand packs about 20 ways to move into a small space: each finger bends at three joints and swings sideways at the knuckle.
- A robot hand that copies yours can have a motor at every joint. This one has 16, where the clamp has one.
- Your fingertips are packed with touch sensors that feel a slip begin. Robot fingers need sensors too; a plain clamp feels nothing.
- A test: turn a held key a quarter turn, using only the fingers. Moving things within the hand is called dexterous manipulation.
Sanctuary announced in-hand manipulation with its 21-DoF hydraulic hands in December 2024Source 9 Source 11. It then showed a sim-trained reinforcement-learning policy reorienting objects against gravity with a 500 g weight added, a vendor-run resultSource 10.
Figure says Helix 02, using Figure 03's fingertip sensors and palm cameras, performs four tasks it describes as manipulation previously out of reach for its stack, in videos it calls fully autonomous and without teleoperation: unscrewing a bottle cap, extracting a single pill from an organizer, a task titled "Push exactly 5 ml from a syringe", and picking small metal parts from clutter. The announcement publishes no task-level success rates, volume calibration, or sensor-ablation resultsSource 6. None of these is the general skill. Each is a task or a task family with its own training run.
In June 2026, Xinghao Zhu, Yuke Zhu and colleagues reported CHORD, a reinforcement-learning framework for long-horizon dexterous manipulation. It compares human and robot motions by the forces and torques they can induce on the object. On 1,831 tasks from its simulated benchmark of 4,739 bimanual tasks, it averaged 82.12% success. Its learned policies transferred to the real worldSource 25.
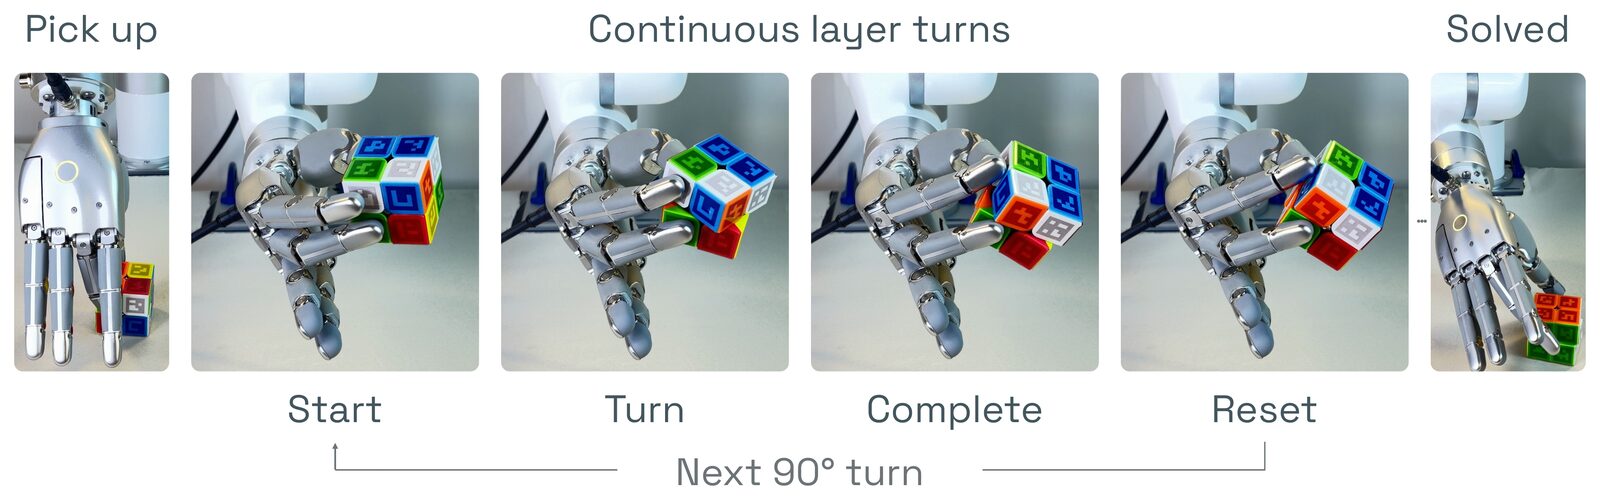
In September 2026, Yutong Liang, Quanquan Peng, Matthew Kim and Xiaolong Wang reported FINGR, a flow policy that turns Rubik's Cube layers with a single real dexterous hand. It succeeded on 99.0% of 300 turn attempts, against 79.7% for the base flow policy. With grasping and table-assisted regrasping added, it solved all ten scrambled 2×2×2 cubes in about 137 seconds on averageSource 27.
In October 2026, Harsh Gupta, Tyler Ga Wei Lum, Jeannette Bohg, Shuran Song and colleagues at Stanford reported that human hand-motion priors help most when they structure exploration and leave the action space unchanged. Their EigenDEXplore adds noise along eigenvectors of human hand motion to ordinary joint-space noise. Across several dexterous hands, it outperformed joint-space and learned action-space baselines in grasping, in-hand reorientation and contact-rich manipulation, with the largest gains where rewards and curricula were least engineeredSource 30.
Deformables and the long tail
A wooden block rests on one of six sides. A towel can be bunched up in more ways than any state estimator will ever enumerate, and some tasks add water, grease, or peanut butterSource 3. Cloth, liquids, and compliant packaging fill Holson's task list: hang a dress shirt that starts with one sleeve inside out, clean peanut butter off your own manipulator.
RL-100 folds cloth and ran a juicing robot in a shopping mall for about seven hours without failure, both per-task results earned through on-robot reinforcement learningSource 23. Physical Intelligence's π0.7 does laundry and espresso tasks with language steeringSource 22.
Physical Intelligence fine-tuned its π0.6-based model on Holson's tasks and took gold in three of five categories with under nine hours of data for most tasks. The model averaged 52% success and 72% task progress, against 9% progress for a baseline VLM without robot pretraining. Two gold tasks were physically impossible for its gripper, and peeling an orange needed a tool and did not countSource 21.
In September 2026, Nidhya Shivakumar, Ken Goldberg and colleagues reported TRACE, which traces monochrome cables in both directions. It uses interactive perception primitives to resolve ambiguous crossings. In 110 physical experiments with up to 4 cables and 40 crossings, it traced about 90% of cable length correctly. The strongest prior method, HANDLOOM 2.0, managed about 60%Source 26.
What solved would look like
Dexterity is solved when one policy does Holson's fifteen tasks in unseen homes within ten times Holson's own time, with no per-task data and with published success ratesSource 3. Nobody is close: the best public scoreboard is about half success with per-task trainingSource 21. The open question is which data closes the gap. If Tesla or Figure reach household dexterity from video at scale, the tactile gap was a transitional hardware shortageSource 1 Source 4.
See also
- Hardware Taxonomy
A buyer's guide from SO-101 to Jetson Thor.
- Teleoperation Rigs
ALOHA, GELLO, UMI and VR rigs compared on cost and quality.
- Cross-Embodiment Transfer
How one policy learns from many robot bodies and from humans.
Linked from
- Cross-Embodiment Transfer
How one policy learns from many robot bodies and from humans.
- Action Spaces for Robot Learning
What each action representation gives the learner and asks of the controller.
- Why RL Won Locomotion but Not Manipulation
Walking is cheap to simulate; contact-rich manipulation is not.
- Sim-to-Real Transfer
Domain randomization, distillation, system identification and real-to-sim reconstruction.
- Hardware Taxonomy
A buyer's guide from SO-101 to Jetson Thor.
- Control
PID, LQR, MPC and whole-body QP, the stack under every learned policy.
- Generalization
From pi0.5's three unseen homes to Helix 2.5's 30.
- Competing Theses
Six bets on how robot intelligence gets built.
- The Bear Case
Why this could be another robotics winter.
References
Rodney Brooks, 2025.
https://rodneybrooks.com/why-todays-humanoids-wont-learn-dexterity/
Vaughan G. Macefield, The Journal of Physiology, 2022.
https://doi.org/10.1113/JP282846
Benjie Holson, 2025.
https://generalrobots.substack.com/p/benjies-humanoid-olympic-games
Figure AI, 2025.
https://www.figure.ai/news/project-go-big
Figure AI, 2024.
https://www.prnewswire.com/news-releases/figure-unveils-figure-02-its-second-generation-humanoid-setting-new-standards-in-ai-and-robotics-302214889.html
Sanctuary AI, 2025.
https://sanctuary.ai/news/sanctuary-ai-equips-general-purpose-robots/
Sanctuary AI, 2024.
https://sanctuary.ai/news/sanctuary-ai-demonstrates-in-hand-manipulation-capabilities-for-improved-general-purpose-robot-dexterity/
- Sanctuary AI Leads the Industry in Controlling Advanced Hydraulic Hands Using Reinforcement Learning
Sanctuary AI, 2025.
https://sanctuary.ai/news/sanctuary-ai-controlling-advanced-hydraulic-hands/
RoboZaps, 2026.
https://blog.robozaps.com/b/sanctuary-ai-phoenix-review
Shadow Robot, 2022.
https://shadowrobot.com/how-much-does-a-robot-hand-cost/
Diana Wolf Torres, Alexander W. Torres, 2026.
https://droids.substack.com/p/the-forearm-is-the-new-hand-inside
Joey Klender, Teslarati, 2026.
https://www.teslarati.com/elon-musk-reveals-shocking-tesla-optimus-patent-detail/
RoboZaps, 2026.
https://blog.robozaps.com/b/unitree-h2-review
Carolina Higuera, Akash Sharma, Taosha Fan, Chaithanya Krishna Bodduluri, Byron Boots, Michael Kaess, and 5 more, 2025.
https://arxiv.org/abs/2506.14754
Jianyi Zhou, Feiyang Hong, Yunhao Li, Yicheng Zhao, Yongjue Cen, Zirui Liu, and 6 more, 2026.
https://arxiv.org/abs/2607.07287
Shan Luo, Nathan F. Lepora, Wenzhen Yuan, Kaspar Althoefer, Gordon Cheng, Ravinder Dahiya, IEEE Transactions on Robotics (accepted), 2025.
https://arxiv.org/abs/2508.11261
Carolina Parada, 2026.
https://deepmind.google/blog/gemini-robotics-2-brings-whole-body-intelligence-to-robots/
Physical Intelligence, 2025.
https://www.pi.website/blog/olympics
Bo Ai, Ali Amin, Raichelle Aniceto, Ashwin Balakrishna, Greg Balke, Kevin Black, and 81 more, 2026.
https://www.pi.website/download/pi07.pdf
Kun Lei, Huanyu Li, Dongjie Yu, Zhenyu Wei, Lingxiao Guo, Zhennan Jiang, and 3 more, 2025.
https://arxiv.org/abs/2510.14830
Dantong Niu, Zhuoyang Liu, Zekai Wang, Boning Shao, Zhao-Heng Yin, Anirudh Pai, and 28 more, 2026.
https://arxiv.org/abs/2606.17055
Xinghao Zhu, Zixi Liu, Shalin Jain, Chenran Li, Milad Noori, Michael Andres Lin, and 15 more, 2026.
https://arxiv.org/abs/2607.00033
Nidhya Shivakumar, Ethan Ransing, Josh Zhang, Shamak Gowda, Kevin Yang, Miles Hua, and 3 more, IROS 2026.
https://arxiv.org/abs/2609.29103
Yutong Liang, Quanquan Peng, Matthew Kim, Xiaolong Wang, 2026.
https://arxiv.org/abs/2609.33973
Enyi Wang, Mingxin Wang, Quan Shi, Hetian Guo, Hongyu Wang, Xi Wang, and 9 more, 2026.
https://arxiv.org/abs/2610.00638
Boston Dynamics, 2026.
https://bostondynamics.com/blog/robot-hands-for-modern-ai-and-real-work/
Harsh Gupta, Tyler Ga Wei Lum, Changhao Wang, Chuer Pan, C. Karen Liu, Jeannette Bohg, and 1 more, 2026.
https://arxiv.org/abs/2610.07681
Haonan Chen, Feiyang Wu, Yuxiang Ma, Mustafa Mete, Pengfei Ye, Junxuan Shen, and 8 more, 2026.
https://arxiv.org/abs/2610.04741
Amirhossein Kazemipour, Hehui Zheng, Robert Katzschmann, 2026.
https://arxiv.org/abs/2609.17172
Further reading
Spot a factual error or missing qualification? Report a content correction.