Teleoperation Rigs
ALOHA, GELLO, UMI and VR rigs compared on cost and quality.
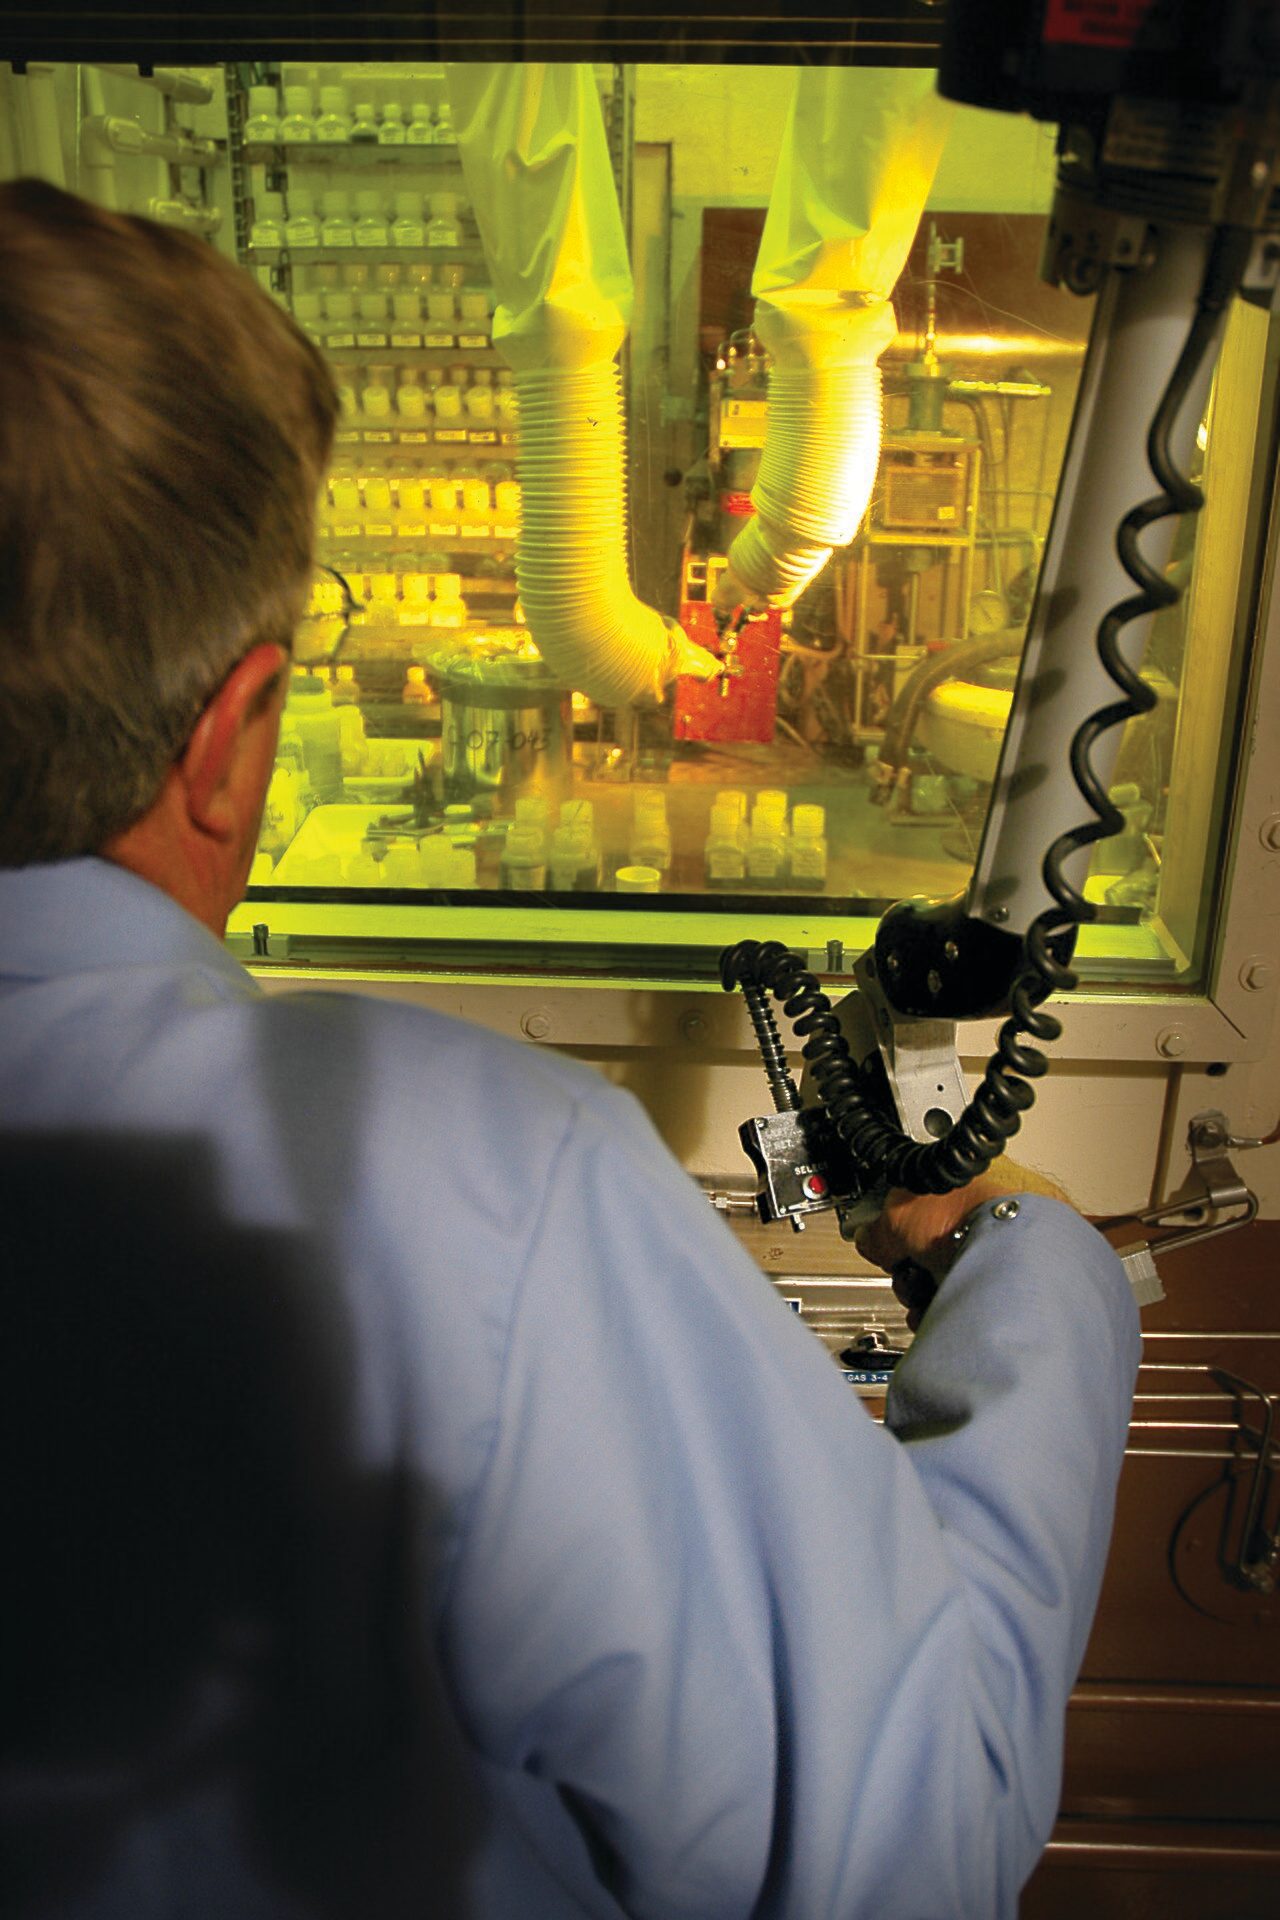
Teleoperation rigs are the hardware a person moves to drive a robot, or a stand-in for one, while a demonstration is recorded. Leader-follower arms, GELLO replicas, UMI handheld grippers and VR headsets trade cost and collection speed against the embodiment gap, and the largest corpora reported by 2026, 100,000 hours and more, came from wearable and handheld devicesSource 11 Source 12.
$300
entry rig
GELLO parts BOM, arm excluded
111/h
UMI collection
demos per hour vs 35/h spacemouse teleop
76k
VR fleet scale
DROID trajectories from 50 operators
not disclosed
workstation USD total
the ACT paper's $18k ALOHA build cost is not a vendor quote
The comparison matrix
Highlight a dimension
4 of 4 rigs
| Sources | |||||
|---|---|---|---|---|---|
| GELLOKinematically matched exoskeletonGELLO for Franka, UR5, and xArm | $300Parts BOM under $300; excludes the target robot arm | highA scaled kinematic twin of the target arm; joint readings map one-to-one onto robot commands | mediumUnder $300 and assembles from printed and catalog parts, but each target arm model needs its own build | lowThe replica shares the arm joint structure, so the operator feels the arm constraints directly | GELLO paperProject site |
| UMIHandheld gripper, no robot at collectionUMI gripper with GoPro wrist camera | $371$73 printed gripper + $298 GoPro and accessories, per gripper | medium155-degree fisheye wrist camera with SLAM-recovered gripper pose; no force channel | high111/h on the cup-arrangement benchmark, over 3x faster than spacemouse teleoperation | mediumA handheld gripper stands in for the robot gripper; latency matching and relative-trajectory actions close the gap at deployment | UMI paperProject site |
| ALOHA-class workstationBimanual leader-follower workstationALOHA 2 (Stanford), Trossen AI Stationary and Mobile AI | not disclosedACT paper (2023): the original ALOHA bimanual setup cost $18k, $20k with optional add-ons such as cameras; a build cost for one configuration, not a vendor quote | highLeader and follower arms share kinematics; demonstrations land directly in the robot joint space at 500 Hz | lowOne operator per fixed workstation; every additional collector costs another full rig | lowThe operator drives a kinematically identical arm, so recorded motion is the robot motion | ACT paperTrossen AI |
| VR teleoperationHeadset plus retargeted human motionDROID Quest 2 rig, Open-TeleVision, Bunny-VisionPro | not disclosed | mediumImmersive stereo view and mirrored motion; actions are retargeted from the operator, not recorded from robot joints | highDROID: 50 operators across 13 institutions collected 76,000 trajectories (350 hours) in 12 months | highHuman hand and controller poses must be remapped through IK onto robot joints; calibration and avoidance layers exist because the mapping drifts | DROIDOpen-TeleVisionBunny-VisionPro |
VR system totals are unpublished; Meta lists the Quest 3S from $299.99Source 13. Try the Cost highlight.
Bimanual workstations: fidelity first
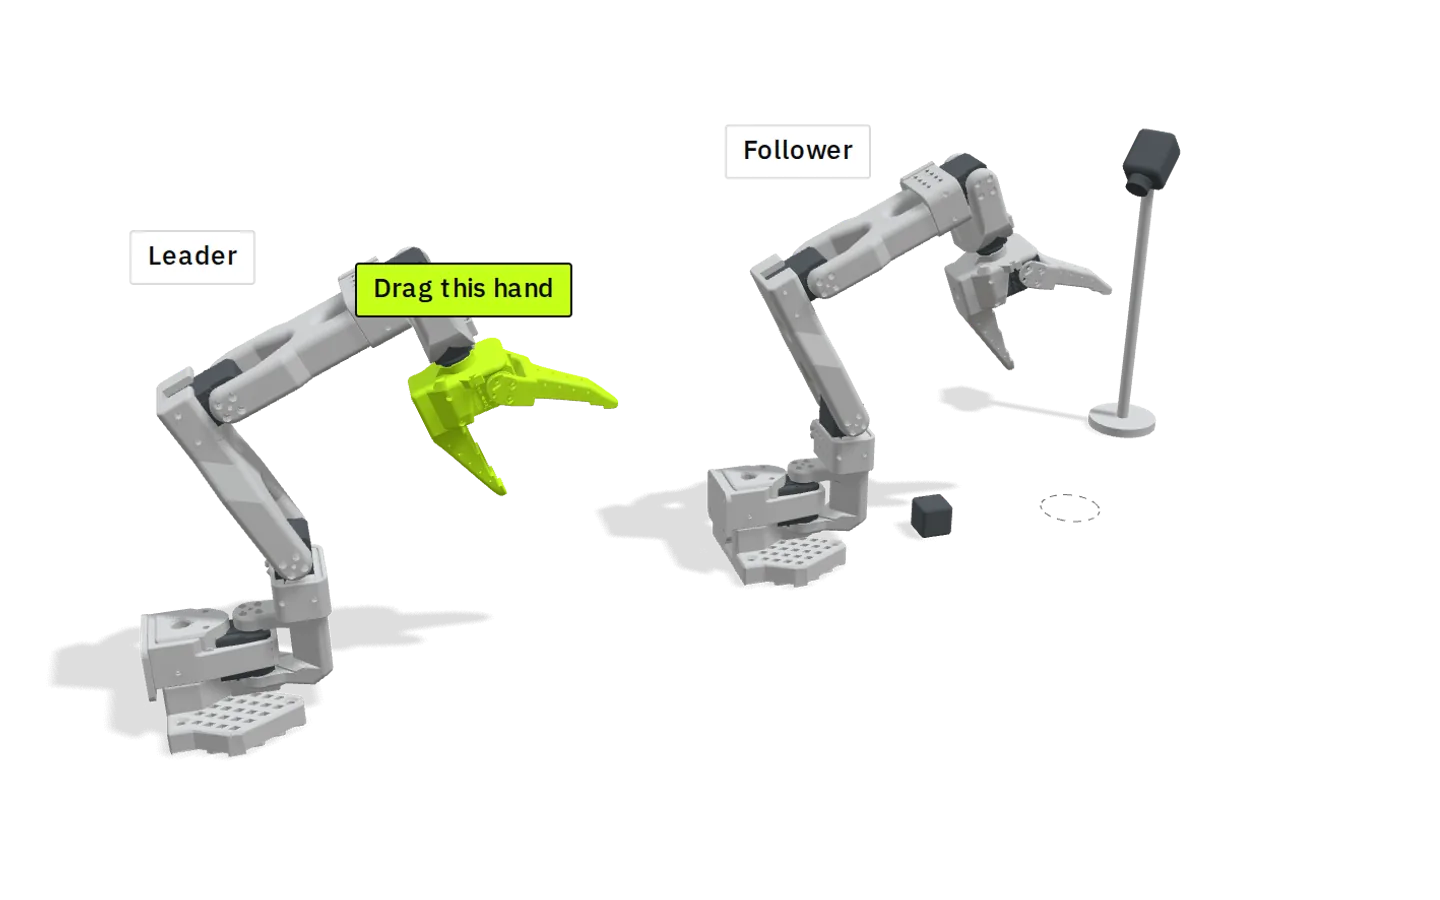
In ALOHA, an operator drives a leader arm that twins the follower, so demonstrations arrive in the robot's joint space. ACT, the action-chunking policy built for that rig, learned six bimanual tasks, each from about 10 minutes of demonstrations. It reached 84 to 96% final success on four of them, 64% on taping and 20% on threading a velcro tie. The paper put the bimanual setup at $18k, or $20k with add-ons such as camerasSource 1. Drag the copy's hand in the figure below and the robot arm mirrors it, recording each moment.
How do robots learn new tasks?
Loading…
A person moves a copy of the arm, and the robot copies every move. Drag the copy's hand: put the block on the circle.
A person steers a copy of the arm, the robot mirrors it, and every moment becomes an example to imitate.
How this was made
The steps in words
- A person moves a copy of the arm, and the robot copies every move. Drag the copy's hand: put the block on the circle.
- While it records, the robot saves what its camera sees and where every joint is, 30 times a second. Each save is one example.
- Each recorded run is a demonstration. After many, the robot learns to copy them and moves alone, beside a faint replay of one.
- Steering a robot through a copy of itself is teleoperation. Learning to repeat the recordings on its own is imitation learning.
Mobile ALOHA added a base; with 50 demonstrations per task and co-training on static ALOHA data, success rose by up to 90% on tasks like sauteing shrimp and opening a two-door wall cabinetSource 2. ALOHA 2's hardware designs are open sourceSource 14. The line now sells as Trossen AI at $23,995.95 for the bimanual Stationary AI, $33,695.95 for Mobile AI and $4,545.95 for a single WidowX AI armSource 3.
Each extra collector needs another workstation. In ALOHA Unleashed, 35 operators without researcher oversight collected over 26,000 episodes for 5 tasks on 10 robots in 2 buildings over 8 monthsSource 15. RT-1's fleet of 13 robots gathered about 130k episodes over 17 monthsSource 16.
GELLO: the kinematic twin
GELLO is a scaled replica of the target arm built from 3D-printed links and off-the-shelf motors, so joint readings map one-to-one onto robot commands. Parts cost under $300; the published designs cover Franka, UR5 and xArm. In its user study, 12 participants ran five tasks on a bimanual pair of UR5 arms, and GELLO was more reliable and faster than VR controllers or a 3D spacemouse. The $300 buys a controller only, and every new arm needs its own designSource 4.
Kinematic twin
The robot copies the leader arm joint for joint
28 degrees
100 degrees
Drag the lit handle; the robot copies each jointShoulder 28 degrees · elbow 100 degrees
Schematic: the copy is exact; sizes, stops and the run are illustrative
How this was made
GELLO is a scaled replica of the arm it drives, built from 3D-printed links and off-the-shelf motors, so each joint's reading maps one to one onto the robot's command for the same joint, with no translation in between. ALOHA's leader arm twins its follower the same way, which is why its demonstrations arrive already in the robot's joint space. The price of the match is that every new arm needs its own replica: GELLO's published designs cover Franka, UR5 and xArm.
The drawing is a leader and its robot on one bench. Both have a shoulder, an elbow and a wrist that keeps the hand pointing down, in the same order, and every link of the small printed leader is the same share of the robot's. Each shoulder and elbow faces you with a dial zeroed the same way on both arms: the shoulder's reads up from level, the elbow's reads the bend down from the upper arm. The lit handle is what the operator holds. The controller at the back passes the leader's readings to the robot unchanged, so the robot's dials always settle on the leader's, and its hand traces the leader's path at the robot's size.
Schematic: a real arm has six or seven joints, and the drawing shows three. The leader's size, the joint stops, the run and the robot's short lag behind the leader are illustrative; the copy from leader to robot is exact.
Wu and colleagues, GELLO (2023); Zhao and colleagues, ALOHA (2023).
A policy trained only on adapted AirExo-2 data performed comparably to one trained on teleoperated dataSource 17. HOMIE's $500 humanoid cockpit pairs an exoskeleton arm and motion-sensing gloves with a pedal-driven locomotion policy, finishing tasks in half the time of earlier systemsSource 18.
JoyLo+, from Wensi Ai, Jiajun Wu, Li Fei-Fei, Ruohan Zhang and colleagues at Stanford and Lambda (October 2026), puts motors on GELLO-style leader arms so they follow the policy, and a touch on a grip hands the whole robot to the operator for a correctionSource 35. The two-arm leader set for a Galaxea R1 Pro costs about $2,515 in partsSource 35. On four real household tasks with 25 trials each, 100 corrections over four retraining rounds raised average success by 81 percentage points, 30 more than 100 extra demonstrationsSource 35.
UMI: collection without a robot
The UMI operator holds a 3D-printed parallel-jaw gripper with a wrist-mounted GoPro and a 155-degree fisheye lens; SLAM recovers the gripper pose from the video. The paper bills the printed gripper at $73 and the GoPro and accessories at $298, for a $371 rigSource 5. On cup arrangement the project site reports 111 demonstrations per hour, against 35 for spacemouse teleoperation and 231 by bare handSource 6.
Demonstrations per hour
Holding the gripper was three times faster than teleoperation
How this was made
The UMI project site reports these rates for one task, arranging a cup. The bare hand records no robot data; it is the speed the gripper is measured against. The spacemouse drives a robot arm directly.
Demonstrations recorded per hour on UMI's cup-arrangement task: 231 by bare hand with no robot, 111 with the UMI handheld gripper and 35 by spacemouse teleoperation of a robot. The UMI gripper ran at 48 percent of bare-hand speed and 3.2 times the teleoperation rate.
Demonstrations per hour, three ways
| collection method | demonstrations per hour |
|---|---|
| Bare hand, no robot | 231 |
| UMI handheld gripper | 111 |
| Spacemouse teleoperation of a robot | 35 |
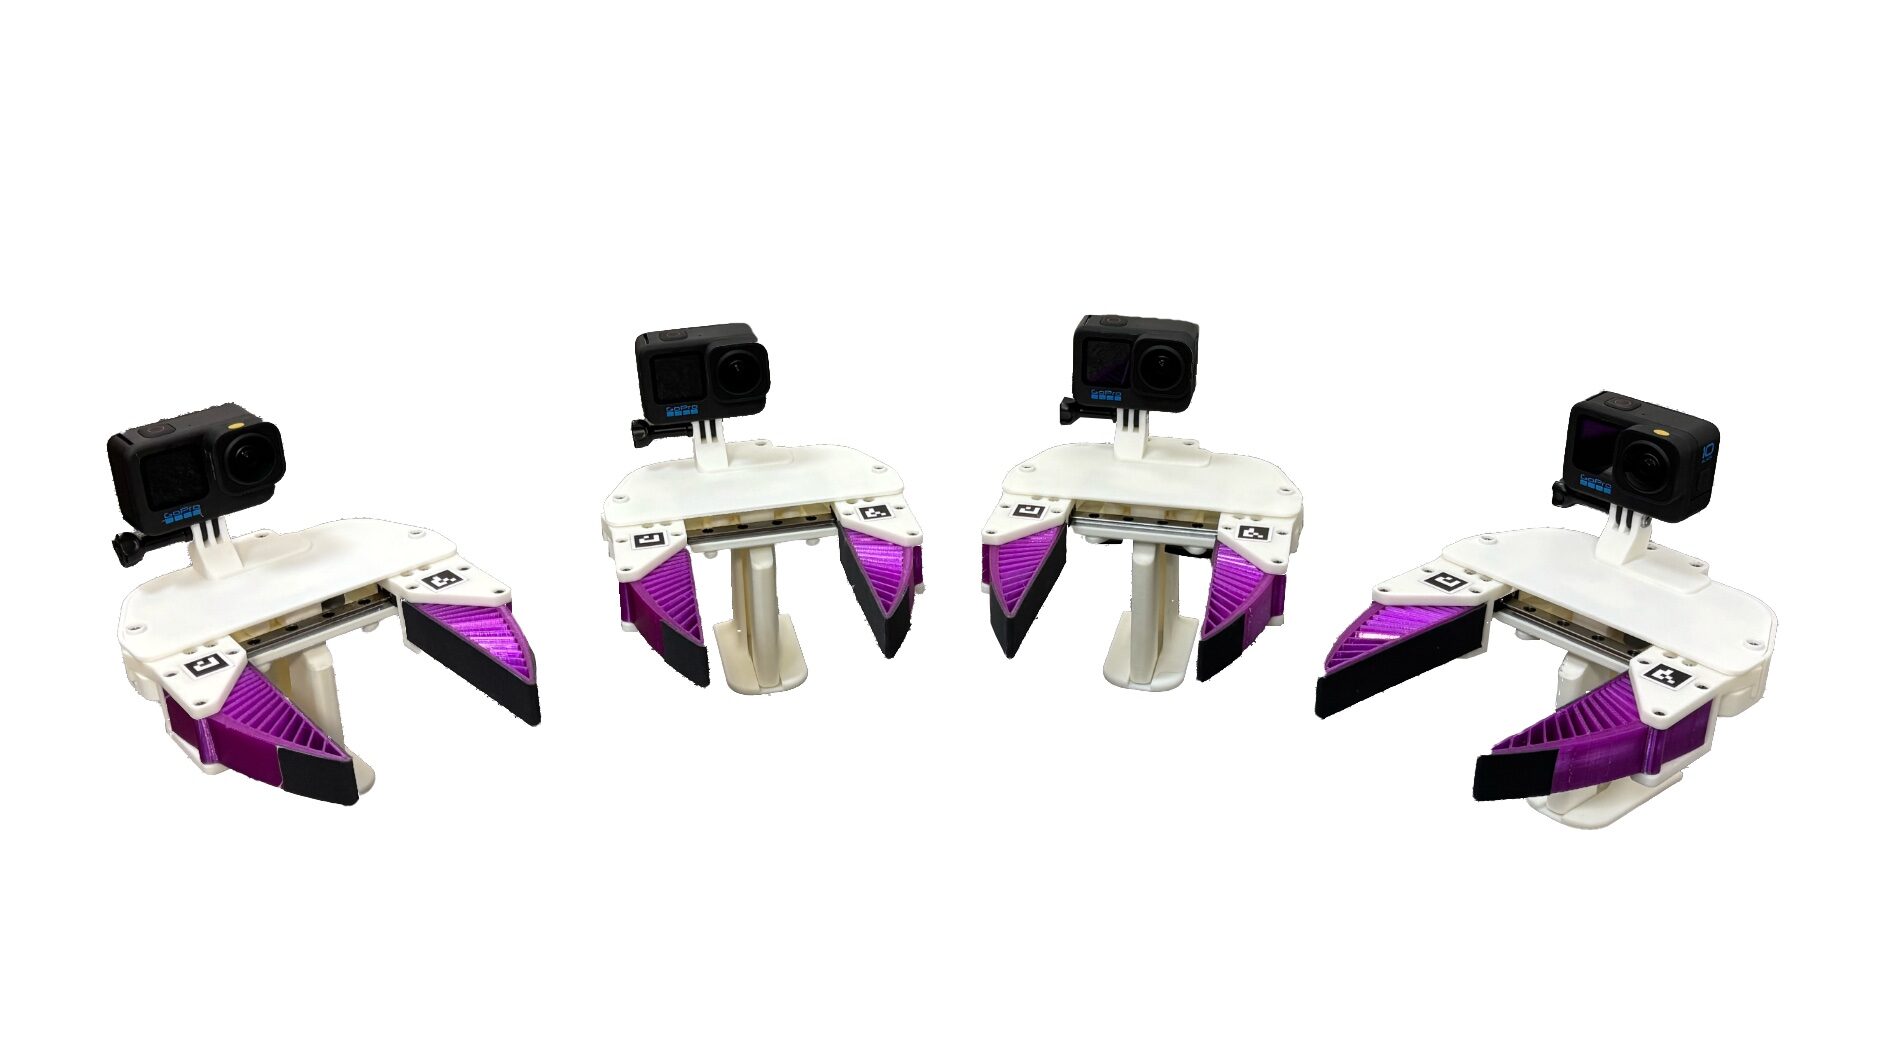
Latency matching at inference time and a camera-relative action representation let UMI policies deploy zero-shot on any arm with a compatible gripper and camera, shown on UR5 and Franka. The data lack a force channelSource 5. ForceMimic adds one: its operator peeled a zucchini in 5 minutes, against over 13 with force-feedback teleoperationSource 19.
Four collectors gathered enough UMI data in one afternoon for about 90% success in new environmentsSource 20. A policy post-trained only on HiFi-UMI data matched in-domain teleoperation across three backbonesSource 21.
Pollen Robotics' Grabette (July 2026) is an open-source handheld recorder modelled on UMI that writes LeRobot datasets, with parts costing about €490. Its motorized twin, Gripette (about €120 in parts), is the robot-arm gripper that carries out the learned movements on a real or simulated armSource 37.
VR teleoperation: scale through headsets
In VR teleoperation the robot mirrors the operator's hand or controller poses through a retargeting layer. In DROID, 50 operators at 13 institutions used Meta Quest 2 headsets on Franka Panda rigs to collect 76,000 trajectories totaling 350 hours over 12 monthsSource 7. Diffusion policies trained on that pool beat the next-best dataset by 22% in-distributionSource 7. RoboTurk's phone interface was statistically similar to VR controllers on task completion timeSource 22.
OPEN TEACH runs on a $500 Meta Quest 3 at up to 90 HzSource 23. Open-TeleVision renders the robot's surroundings in stereo and mirrors the operator's arm and hand motion on two humanoidsSource 8. Bunny-VisionPro adds low-cost haptic feedback and collision and singularity avoidance in retargetingSource 9. The Apple Vision Pro it runs on launched at $3,499Source 10; the October 2025 M5 model keeps that priceSource 24.
Human and robot arms share no kinematics; every action passes through IK and calibration. HumanPlus shadows a person from one RGB camera and reaches 60 to 100% success with up to 40 demonstrationsSource 25.
Gloves and wearables
DexUMI's hand exoskeleton gives the operator direct haptic feedback and adapts human motion to feasible robot-hand motion, for an 86% average success rateSource 26. SEED-UMI collects data 3.0x faster than exoskeleton-based teleoperationSource 27. Sunday's Skill Capture Glove shares its robot hand's geometry and sensor layout; Sunday reports converting glove data to robot data with a 90% success rateSource 28. DITTO-X, from Stanford and Columbia researchers (September 2026), renders joint-level force and fingertip contacts from the robot hand and improved demonstration quality and throughput over a commercial hand-tracking gloveSource 29.
FOMO-Dex, from Ying Yuan, Jitendra Malik and colleagues at Amazon FAR and Carnegie Mellon (October 2026), hands force control to the robot: a controller between the operator's glove and a 22-DoF hand applies force-driven corrections along selected directions and leaves the rest of each command unchangedSource 36. After 10 minutes of practice, four operators collected 30.7 minutes of successful screwdriving demonstrations per hour, against 12.4 with stiff controlSource 36. Policies cloned from 50 such demonstrations averaged 6.3 screw turns per episode over 10 trials, against 0.6 from stiff-control dataSource 36.
PanTact, from Xiaomeng Xu, Shuran Song, Guanya Shi and colleagues at Stanford, Amazon FAR and Carnegie Mellon (October 2026), pairs bimanual UMI grippers with force-sensing patches on the demonstrator's forearms and knees, so each demonstration records where and when the body touches the scene. A Unitree G1 with no body contact sensors, trained on 100 or 110 such demonstrations per task, grasped a small object and then embraced a bulky one in 17 of 20 trials, and carried a box while pushing another with its legs in 9 of 10. Trained on the same demonstrations, a humanoid UMI baseline that tracked only the grippers consistently failed to support the bulky objectSource 30.
Boston Dynamics argues that wearables capture only proxy signals for controlling a dexterous hand, and that reinforcement learning in simulation is an essential componentSource 31. EgoMimic found an extra hour of hand data worth more than an extra hour of robot dataSource 32. Apple's EgoDex recorded 829 hours with Vision Pro hand trackingSource 33; Generalist AI reports over 270,000 hours for GEN-0Source 34.
Choosing by axis
Leader arms and GELLO leave the smallest gap between collection and deployment; UMI, gloves and headsets scale across scenes, as DROID didSource 7. The Data Bottleneck covers what the extra hours buy.
See also
- Action Chunking (ACT and ALOHA)
ACT predicts short action sequences and smooths them with temporal ensembling.
- Major Datasets
The major open robot datasets and what each collected.
- Humanoid Whole-Body Control
How humanoids track retargeted human motion.
Linked from
- Behavior Cloning Foundations
Covariate shift makes naive imitation drift, and DAgger is the standard fix.
- Action Chunking (ACT and ALOHA)
ACT predicts short action sequences and smooths them with temporal ensembling.
- Diffusion Policy
Visuomotor control as conditional denoising over action sequences, with receding-horizon execution.
- Cross-Embodiment Transfer
How one policy learns from many robot bodies and from humans.
- Humanoid Whole-Body Control
How humanoids track retargeted human motion.
- Major Datasets
The major open robot datasets and what each collected.
- The Robot Learning Stack
From data capture to robot integration as one reproducible system.
- Kinematics
How joint angles place a robot's hand, and the reverse.
- Dexterity
Contact-rich manipulation, touch sensing, in-hand reorientation and deformables.
- Competing Theses
Six bets on how robot intelligence gets built.
References
Tony Z. Zhao, Vikash Kumar, Sergey Levine, Chelsea Finn, RSS 2023.
https://arxiv.org/abs/2304.13705
Zipeng Fu, Tony Z. Zhao, Chelsea Finn, 2024.
https://arxiv.org/abs/2401.02117
Philipp Wu, Yide Shentu, Zhongke Yi, Xingyu Lin, Pieter Abbeel, 2023.
https://arxiv.org/abs/2309.13037
Cheng Chi, Zhenjia Xu, Chuer Pan, Eric Cousineau, Benjamin Burchfiel, Siyuan Feng, and 2 more, 2024.
https://arxiv.org/abs/2402.10329
Cheng Chi, Zhenjia Xu, Chuer Pan, Eric Cousineau, Benjamin Burchfiel, Siyuan Feng, and 2 more, 2024.
https://umi-gripper.github.io/
Alexander Khazatsky, Karl Pertsch, Suraj Nair, 2024.
https://arxiv.org/abs/2403.12945
Xuxin Cheng, Jialong Li, Shiqi Yang, Ge Yang, Xiaolong Wang, 2024.
https://arxiv.org/abs/2407.01512
Runyu Ding, Yuzhe Qin, Jiyue Zhu, Chengzhe Jia, Shiqi Yang, Ruihan Yang, and 2 more, 2024.
https://arxiv.org/abs/2407.03162
Apple, 2024.
https://www.apple.com/newsroom/2024/01/apple-vision-pro-available-in-the-us-on-february-2/
Generalist Team, Generalist AI blog, 2026.
https://generalistai.com/blog/gen-1
Xiaomi Robotics Team, Jun Guo, Piaopiao Jin, Jason Li, Peiyan Li, Yingyan Li, and 28 more, 2026.
https://arxiv.org/abs/2607.15330
Meta, Meta Newsroom, 2024.
https://about.fb.com/news/2024/09/meta-quest-3s-our-most-affordable-mixed-reality-headset/
ALOHA 2 Team, Jorge Aldaco, Travis Armstrong, Robert Baruch, Jeff Bingham, Sanky Chan, and 20 more, 2024.
https://arxiv.org/abs/2405.02292
Tony Z. Zhao, Jonathan Tompson, Danny Driess, Pete Florence, Kamyar Ghasemipour, Chelsea Finn, and 1 more, 2024.
https://arxiv.org/abs/2410.13126
Anthony Brohan, Noah Brown, Justice Carbajal, Yevgen Chebotar, Joseph Dabis, Chelsea Finn, and 45 more, 2022.
https://arxiv.org/html/2212.06817v2
Hongjie Fang, Chenxi Wang, Yiming Wang, Jingjing Chen, Shangning Xia, Jun Lv, and 8 more, 2025.
https://arxiv.org/abs/2503.03081
Qingwei Ben, Feiyu Jia, Jia Zeng, Junting Dong, Dahua Lin, Jiangmiao Pang, 2025.
https://arxiv.org/abs/2502.13013
Wenhai Liu, Junbo Wang, Yiming Wang, Weiming Wang, Cewu Lu, 2024.
https://arxiv.org/abs/2410.07554
Fanqi Lin, Yingdong Hu, Pingyue Sheng, Chuan Wen, Jiacheng You, Yang Gao, ICLR 2025, 2024.
https://arxiv.org/abs/2410.18647
Simple AI, Yuteng Wei, Jinming Ma, Jiawei Wang, Weitao Zhou, Yushen Zuo, and 12 more, 2026.
https://arxiv.org/abs/2607.25895
Ajay Mandlekar, Yuke Zhu, Animesh Garg, Jonathan Booher, Max Spero, Albert Tung, and 6 more, CoRL 2018.
https://arxiv.org/abs/1811.02790
Aadhithya Iyer, Zhuoran Peng, Yinlong Dai, Irmak Guzey, Siddhant Haldar, Soumith Chintala, and 1 more, 2024.
https://arxiv.org/abs/2403.07870
Apple, Apple Newsroom, 2025.
https://www.apple.com/newsroom/2025/10/apple-vision-pro-upgraded-with-the-m5-chip-and-dual-knit-band/
Zipeng Fu, Qingqing Zhao, Qi Wu, Gordon Wetzstein, Chelsea Finn, 2024.
https://arxiv.org/abs/2406.10454
Mengda Xu, Han Zhang, Yifan Hou, Zhenjia Xu, Linxi Fan, Manuela Veloso, and 1 more, 2025.
https://arxiv.org/abs/2505.21864
Tengbo Yu, Jiahao Wu, Daohan Li, Bingxu Chen, Hao Liu, Xiaojian Ma, and 1 more, 2026.
https://arxiv.org/abs/2609.11753
Sunday Team, Sunday Robotics blog, 2025.
https://www.sunday.ai/blog/no-robot-data
Zhanpeng He, Joaquin Palacios, Zhangyu Wang, Chenhao Li, Katelyn Lee, Matei Ciocarlie, and 2 more, 2026.
https://arxiv.org/abs/2610.00781
Xiaomeng Xu, Han Zhang, Zhian Ruan, Xiaofeng Guo, Jinkun Cao, Ruihan Yang, and 3 more, 2026.
https://arxiv.org/abs/2610.12558
Boston Dynamics, 2026.
https://bostondynamics.com/blog/robot-hands-for-modern-ai-and-real-work/
Simar Kareer, Dhruv Patel, Ryan Punamiya, Pranay Mathur, Shuo Cheng, Chen Wang, and 2 more, 2024.
https://arxiv.org/abs/2410.24221
Ryan Hoque, Peide Huang, David J. Yoon, Mouli Sivapurapu, Jian Zhang, ICLR 2026, 2025.
https://arxiv.org/abs/2505.11709
Generalist Team, Generalist AI blog, 2025.
https://generalistai.com/blog/gen-0
Wensi Ai, Christopher Luey, Karthik Dharmarajan, Evans Han, Yunfan Jiang, Stef Ren, and 4 more, 2026.
https://arxiv.org/abs/2610.17748
Ying Yuan, David Held, Jitendra Malik, Haozhi Qi, 2026.
https://arxiv.org/abs/2610.17161
Steve Nguyen, Claire Houziel, Gaelle Lannuzel, Simon Le Goff, Jeremy Laville, Étienne, Hugging Face blog, 2026-07-21.
https://huggingface.co/blog/grabette
Spot a factual error or missing qualification? Report a content correction.