Kinematics
How joint angles place a robot's hand, and the reverse.
Kinematics is the geometry of robot motion, studied without forces or torques. Forward kinematics maps joint angles to the end-effector pose through a unique composition of transforms, and inverse kinematics maps a pose back to joint angles, with no solution, one, or manySource 3.
Forward kinematics
Turn the shoulder and everything beyond it swings along
Pose the whole arm
Adjust more
shoulder 110°; hand at x +0.45, y +1.89 link units from the shoulder
Turn the shoulder: the elbow, wrist and pen ride alongShoulder 110 degrees · hand 0.45 right, 1.89 out
Schematic: one grid square is half a link
How this was made
Computed on chosen link lengths of 1.00, 0.75 and 0.55 link units, so the hand reaches at most 2.30 from the shoulder. Each angle is measured from the link before it, anticlockwise positive, and the hand's position is the running sum of the three link vectors. The shoulder turns from 0 degrees (pointing right) to 180 (pointing left); the elbow and wrist turn up to 180 degrees either way. In the drawing each joint's dial rides on the link before it and the next link is its pointer; the shoulder's dial is the protractor on the paper, and one grid square is half a link unit. The faint sketch on the paper is the pose before the last move; at load it is the opening pose with the shoulder 40 degrees back, and the inked arc is the path the pen swept while only the shoulder turned.
With the shoulder at 110 degrees, the elbow at -45 degrees and the wrist at -35 degrees, the hand sits at x +0.45, y +1.89 link units from the shoulder; the three links are 1.00, 0.75 and 0.55 long.
Current arm pose
- shoulder
- 110°
- elbow
- -45°
- wrist
- -35°
- hand x
- +0.45
- hand y
- +1.89
4
DH parameters per joint
theta, d, a, alpha
5
SO-101 arm joints
plus a gripper, in the 3D playground
±0.5mm
playground IK tolerance
solver residual target
3
joints in the 2D demo
the planar chain above
Forward kinematics
A serial arm is a chain of rigid links and joints, with a coordinate frame on each link. A rigid transform packs a rotation and a translation into one matrixSource 3:
The ordered product of one transform per joint carries the base frame to the tool frameSource 3:
The map is smooth in the joint angles and cheap to evaluateSource 3. In the plane, each link is a vector of length along the cumulative angle, and the end effector sits at their sumSource 1:
Moving one joint moves every later link, the dependence the Jacobian capturesSource 3.
Denavit-Hartenberg parameters
Denavit and Hartenberg's 1955 matrix notation describes the kinematics of all lower-pair mechanismsSource 7. LaValle gives the Denavit-Hartenberg convention four parameters per revolute joint: an offset along a rotation axis, an angle about it, the distance between successive axes, and the angle between themSource 1. The example here writes the last two and .
Standard and modified variants coexistSource 8. The standard form isSource 8:
A planar arm has zero twists and offsets, leaving link lengths and anglesSource 1.
| Joint i | θi | di | ai | αi |
|---|---|---|---|---|
| 1 (base) | θ1 | 0 | 1.00 | 0 |
| 2 (elbow) | θ2 | 0 | 0.75 | 0 |
| 3 (wrist) | θ3 | 0 | 0.55 | 0 |
DH parameters are ill-conditioned when consecutive axes are nearly parallelSource 3. Product-of-exponentials (POE) parameters vary smoothly as the axes changeSource 9: POE, which Brockett applied to manipulators in 1984, treats each joint as a screw about a fixed axis, the form Modern Robotics usesSource 10 Source 3.
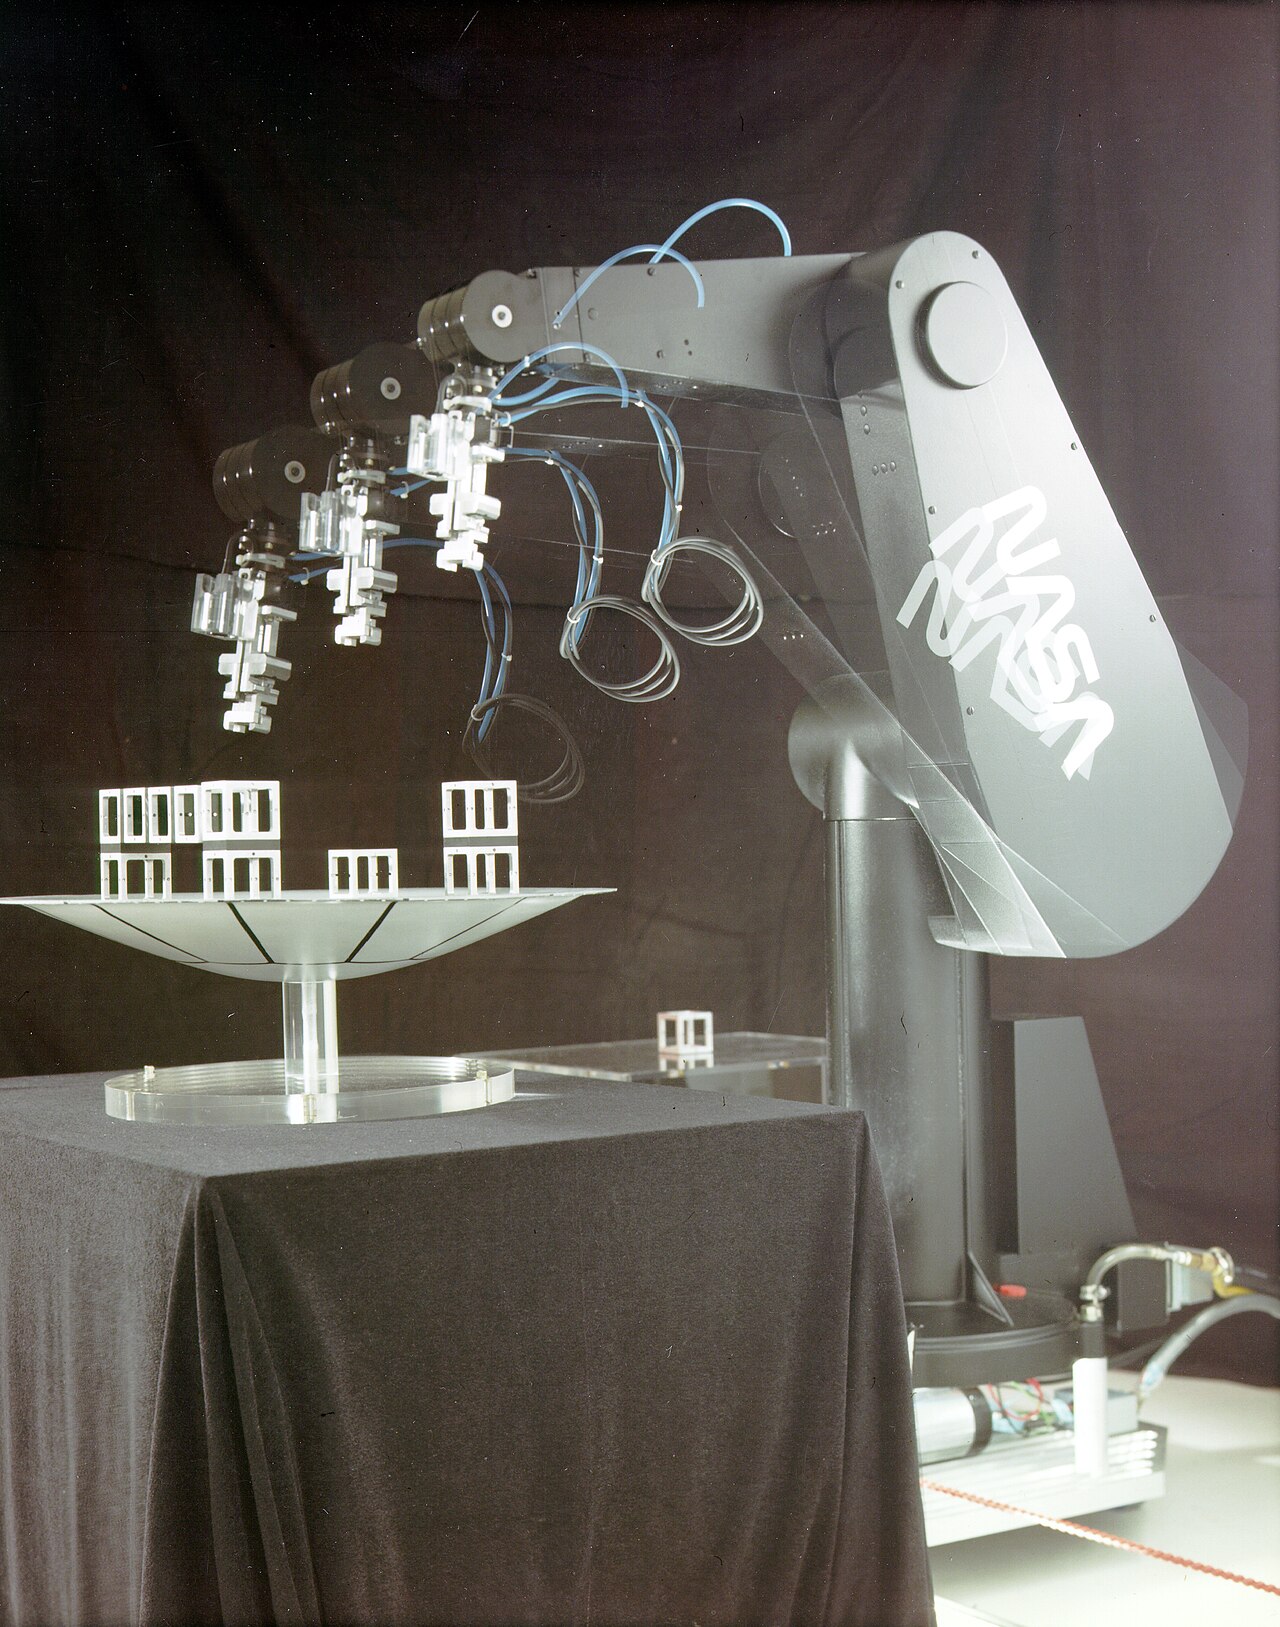
The 3D playground reads the SO-101 chain from its URDF, the most common description format, where each joint carries an origin transform and a rotation axisSource 4 Source 11.
The Jacobian
The Jacobian relates joint velocities to end-effector velocity, one column per jointSource 3:
In Modern Robotics' space Jacobian, column is joint 's screw axis at the current pose, in base-frame coordinatesSource 3. A revolute joint with unit axis through point gives the first form, and a prismatic joint sliding along unit direction the secondSource 3:
The transpose maps an end-effector wrench to balancing joint torques, Source 3. At singularities, such as a fully extended arm, the Jacobian loses rank, and nearby a modest end-effector speed demands unbounded joint speedsSource 3; Yoshikawa's 1985 manipulability measure scores how well an arm can position and orient its end effectorSource 12.
Whitney's resolved motion rate control (1969) let an operator command hand motion along task axesSource 2, with the inverse Jacobian giving joint rates:
A redundant arm uses the pseudoinverse , whose spare freedom can serve goals such as avoiding joint limitsSource 3, ranked against the end-effector task in Siciliano and Slotine's task-priority frameworkSource 13. Near singular points, Nakamura and Hanafusa's singularity-robust inverse returns a motion close to the desired pathSource 14.
Inverse kinematics
Inverse kinematics seeks with for a target . The map is nonlinear: a reachable target can have several configurations, such as elbow left or right, a redundant arm has a continuum, and an unreachable target has noneSource 3. Move the shoulder slider in the figure below to trace the hand's path, then drag the cup and watch the arm work out an angle for every joint.
How does a robot arm reach a cup?
Loading…
An arm only controls its joints. Turn the shoulder and the hand swings in an arc.
To reach a cup an arm must work out every joint's angle, and some spots stay out of reach.
How this was made
The steps in words
- An arm only controls its joints. Turn the shoulder and the hand swings in an arc.
- To pick up a cup, the robot must find an angle for every joint at once. Drag the cup and watch it work them out.
- Now the cup slides much further away.
- Some places can be reached two ways: elbow up or elbow down. The faint arm shows the other way.
- Turning joints to see where the hand goes is forward kinematics. Working backwards from the hand to the joints is inverse kinematics.
Closed forms exist for special geometries, such as six-revolute arms with intersecting wrist axesSource 3. A general 6R arm reduces to one minimum-degree polynomial in a single joint variableSource 15, which Manocha and Canny's 1994 algorithm solved in 11 ms on average on an IBM RS/6000 workstationSource 16, and Diankov's IKFast generates closed-form solvers that answer in about 6 microseconds, against about 10 milliseconds for most numerical solversSource 17. The general tool is iterative: linearize, step, repeatSource 3:
KDL's pseudoinverse solver repeatedly reports false failures on humanoids, and TRAC-IK finds solutions much more oftenSource 18. cuRobo solves over 7,000 collision-free IK queries per secondSource 19, and for redundant arms IKFlow samples 2,000 solutions in under 10 ms, within 10 mm and 2 degrees of exactSource 20. The 3D kinematics playground solves IK on TheRobotStudio's SO-101 arm with a live residual and iteration countSource 4.
The same geometry, inside learned policies
Action chunking with ACT predicts 14 joint-space targets for two 6-DoF arms and their grippersSource 5, while OpenVLA predicts 7-dimensional single-arm end-effector actionsSource 21, and Diffusion Policy did consistently better with position than velocity actionsSource 22.
Across 13,000+ real rollouts and 500+ models, delta actions consistently helped, joint space favored stability, and task space favored generalizationSource 23.
GR00T N1 uses embodiment-specific action decoders: in its simulation benchmarks a Panda arm acts in relative end-effector position and rotation, and the GR-1 humanoid in joint positionsSource 24. NVIDIA says N1.7 shares one relative end-effector action space across robot and human dataSource 6.
Quaternions and Euler angles are discontinuous and hard for networks to learn, while 5D and 6D rotation representations are continuousSource 25.
Teleoperation runs through the same chain: a GELLO leader copies its target arm's kinematic structureSource 26, and retargeting artifacts such as foot sliding reduce the robustness of humanoid tracking policiesSource 27.
Treat coordinate frames as an API
A Cartesian action must name its frame, units, rotation representation, composition order, and whether it is absolute or relative; a joint action needs joint order, signs, limits and controller semantics. ROS REP 103 makes frames right-handed, with x forward, y left and z upSource 28, and REP 105 separates the drifting odom frame from the map frame, which can jumpSource 29.
Round-trip kinematics tests and versioned URDF and calibration files keep the contract testable. LeRobot calibrates SO-101 leader and follower arms to read the same values in the same pose, so a network trained on one robot works on anotherSource 30. See the calibration guide and the action-space guide.
See also
- Cross-Embodiment Transfer
How one policy learns from many robot bodies and from humans.
- Teleoperation Rigs
ALOHA, GELLO, UMI and VR rigs compared on cost and quality.
Linked from
- Robot Learning Curriculum for ML Engineers
A dependency-ordered route from supervised learning to real robot policies.
- Action Spaces for Robot Learning
What each action representation gives the learner and asks of the controller.
- Motion Planning
Configuration space, RRT and its variants, and trajectory optimization.
- Control
PID, LQR, MPC and whole-body QP, the stack under every learned policy.
- State Estimation
Kalman filters, factor graphs, and pose estimation from noisy sensors.
- Grasp Planning
Contact mechanics, grasp quality metrics, and force closure.
- Robot Calibration
The measurements that make sensor coordinates agree with motion.
References
Daniel E. Whitney, IEEE Trans. Man-Machine Systems, 1969.
https://doi.org/10.1109/TMMS.1969.299896
Kevin M. Lynch, Frank C. Park, Cambridge University Press, 2017.
https://hades.mech.northwestern.edu/index.php/Modern_Robotics
Tony Z. Zhao, Vikash Kumar, Sergey Levine, Chelsea Finn, RSS 2023.
https://arxiv.org/abs/2304.13705
P. I. Corke, IEEE Trans. Robotics, 2007.
https://doi.org/10.1109/TRO.2007.896765
Koichiro Okamura, F. C. Park, Robotica, 1996.
https://doi.org/10.1017/S0263574700019810
R. W. Brockett, Mathematical Theory of Networks and Systems (LNCIS 58), 1984.
https://doi.org/10.1007/BFb0031048
Daniella Tola, Peter Corke, 2023.
https://arxiv.org/abs/2308.00514
Tsuneo Yoshikawa, Int. J. Robotics Research, 1985.
https://doi.org/10.1177/027836498500400201
B. Siciliano, J.-J. E. Slotine, Fifth International Conference on Advanced Robotics (ICAR '91), 1991.
https://doi.org/10.1109/ICAR.1991.240390
Yoshihiko Nakamura, Hideo Hanafusa, ASME J. Dynamic Systems, Measurement, and Control, 1986.
https://doi.org/10.1115/1.3143764
M. Raghavan, B. Roth, ASME J. Mechanical Design, 1993.
https://doi.org/10.1115/1.2919218
D. Manocha, J. F. Canny, IEEE Trans. Robotics and Automation, 1994.
https://doi.org/10.1109/70.326569
Rosen Diankov, PhD thesis, Carnegie Mellon University Robotics Institute (CMU-RI-TR-10-29), 2010.
https://www.ri.cmu.edu/publications/automated-construction-of-robotic-manipulation-programs/
Patrick Beeson, Barrett Ames, IEEE-RAS Humanoids 2015.
https://doi.org/10.1109/HUMANOIDS.2015.7363472
Balakumar Sundaralingam, Siva Kumar Sastry Hari, Adam Fishman, Caelan Garrett, Karl Van Wyk, Valts Blukis, and 6 more, 2023.
https://arxiv.org/abs/2310.17274
Barrett Ames, Jeremy Morgan, George Konidaris, 2021.
https://arxiv.org/abs/2111.08933
Moo Jin Kim, Karl Pertsch, Siddharth Karamcheti, Ted Xiao, Ashwin Balakrishna, Suraj Nair, and 12 more, 2024.
https://arxiv.org/abs/2406.09246
Cheng Chi, Zhenjia Xu, Siyuan Feng, Eric Cousineau, Yilun Du, Benjamin Burchfiel, and 2 more, 2023.
https://arxiv.org/abs/2303.04137
Yuchun Feng, Jinliang Zheng, Zhihao Wang, Dongxiu Liu, Jianxiong Li, Jiangmiao Pang, and 2 more, 2026.
https://arxiv.org/abs/2602.23408
NVIDIA, Johan Bjorck, Fernando Castañeda, Nikita Cherniadev, Xingye Da, Runyu Ding, and 36 more, 2025.
https://arxiv.org/abs/2503.14734
Yi Zhou, Connelly Barnes, Jingwan Lu, Jimei Yang, Hao Li, 2018.
https://arxiv.org/abs/1812.07035
Philipp Wu, Yide Shentu, Zhongke Yi, Xingyu Lin, Pieter Abbeel, 2023.
https://arxiv.org/abs/2309.13037
Joao Pedro Araujo, Yanjie Ze, Pei Xu, Jiajun Wu, C. Karen Liu, 2025.
https://arxiv.org/abs/2510.02252
Tully Foote, Mike Purvis, ROS Enhancement Proposals, 2010.
https://www.ros.org/reps/rep-0103.html
Wim Meeussen, ROS Enhancement Proposals, 2010.
https://www.ros.org/reps/rep-0105.html
Hugging Face, LeRobot Documentation, as of 2026-10-02.
https://huggingface.co/docs/lerobot/so101
Further reading
Chung Min Kim, Brent Yi, Hongsuk Choi, Yi Ma, Ken Goldberg, Angjoo Kanazawa, 2025.
https://arxiv.org/abs/2505.03728
Seyed Alireza Azimi, Homayoon Farrahi, Abhishek Naik, Colin Bellinger, A. Rupam Mahmood, 2026.
https://arxiv.org/abs/2606.18594
GEAR Team, Allison Azzolini, Johan Bjorck, Valts Blukis, Fernando Castañeda, Rahul Chand, and 53 more, 2025.
https://research.nvidia.com/labs/gear/gr00t-n1_6/
Erik Bauer, Elvis Nava, Robert K. Katzschmann, 2025.
https://arxiv.org/abs/2506.14608
Spot a factual error or missing qualification? Report a content correction.