Grasp Planning
Contact mechanics, grasp quality metrics, and force closure.
Grasp planning is the choice of contact locations and forces that let a hand hold an object against disturbancesSource 6. Its central test, force closure, asks whether the origin lies inside the convex hull of the contact wrenchesSource 1; the distance to that hull's boundary is the standard quality metricSource 5.
The wrench space, live
Grasp quality (force closure)
Three well-placed fingers hold firm against any push
Adjust more
The same grip as forces and twists: each dot is one edge of a friction cone. The grip holds while the ring where the axes cross sits inside the shaded hull.
Drag a finger round the block; inside its wedge a finger can push without slippingPulls from every direction are resisted: the grip holds
Schematic: computed for an ideal block, not measured on a robot
How this was made
Seen on the test table, the block is a square of half side 1 and each fingertip is a point contact. Friction lets a contact push anywhere inside its friction cone, drawn as the wedge on the block's top at each fingertip, of half-angle arctan μ, but never pull; at μ 0.70 the half-angle is 35.0°. The surface slider sets μ from 0.05 to 1.00.
The two edge forces of each cone, with their torque τ about the centre measured per half side, are the primitive wrenches (fx, fy, τ). Their convex hull is the grasp wrench space drawn under Adjust more. Force closure holds exactly when the origin sits strictly inside the hull: the fingertips can then balance any push or twist. The dial shows the Ferrari-Canny quality ε, the radius of the largest origin-centred ball inside the hull. The dial rests on its zero stop exactly when ε = 0 and the grip fails; any reading above that is a grip that holds. The three-finger grasp at μ 0.70 gives ε = 0.444; the dial reads full at ε = 1.00, which four fingertips at the edge midpoints reach on the roughest surface.
The eight test forces act through the centre, 45° apart: a cord tied to an eye bolt on the block's edge, on the line through its centre, pulls it toward each station on the rim in turn: the same force as a push through the centre from the opposite side. A pull counts as resisted when a non-negative mix of the primitive wrenches supplies the opposite force with no net twist; its telltale pin then stands up, lit, and under force closure every pin is up. A pull the grip cannot cancel drags the block toward the station during the test.
Contact positions run counterclockwise from 0.000 at the top-right corner of the square as the model draws it, which is the far right corner on the table, so the edge midpoints are 0.125, 0.375, 0.625 and 0.875. A dragged fingertip snaps to the 0.005 grid of the contact sliders; the pips on each finger's base give its number.
contacts 3 · force closure yes · ε 0.444 · friction coefficient μ 0.70
3 frictional contacts on the unit square at mu 0.70 open inward cones of half-angle 35.0 degrees; each contact can push along its cone but cannot pull.
Current object contacts and cones
- contacts
- 3
- mu
- 0.70
- cone half-angle
- 35.0°
- regime
- push-only cones, closed grasp
The grasp wrench hull of 3 contacts currently reports force closure yes with Ferrari-Canny quality epsilon 0.444; that radius is the largest origin-centered wrench ball that still fits inside the hull.
Current wrench-space quality
- force closure
- yes
- epsilon
- 0.444
- origin
- inside the hull
- contacts
- 3
Contact models
3
Planar contacts, frictional
minimum for a generic object (Murray, Li, Sastry)
4
Spatial contacts, frictional
same bound in three dimensions
7-12
Frictionless spatial
Somoff's lower bound, Markenscoff's upper
6.7M
Dex-Net 2.0 training datapoints
synthetic depth/grasp examples with analytic binary labels; not robot trials
A contact model says which forces a fingertip can transmit; Salisbury and Roth modeled several finger-contact types for three-fingered handsSource 10. A frictionless point contact pushes only along the surface normal. A point contact with friction obeys Coulomb's law: the tangential force can reach times the normal force before the contact slidesSource 1.
The admissible forces form the friction cone around the inward normal, with half-angle . In the plane the cone is a wedge; in space it is a quadratic cone, and approximating it by a polyhedral one keeps the analysis linearSource 1 Source 7. A soft-finger contact adds a torsional moment about the normal, bounded by a torsional coefficient times the normal loadSource 1. Tilt the grip in the figure below and pick a surface to find where the pinch lets go.
Why do robots drop things?
Loading…
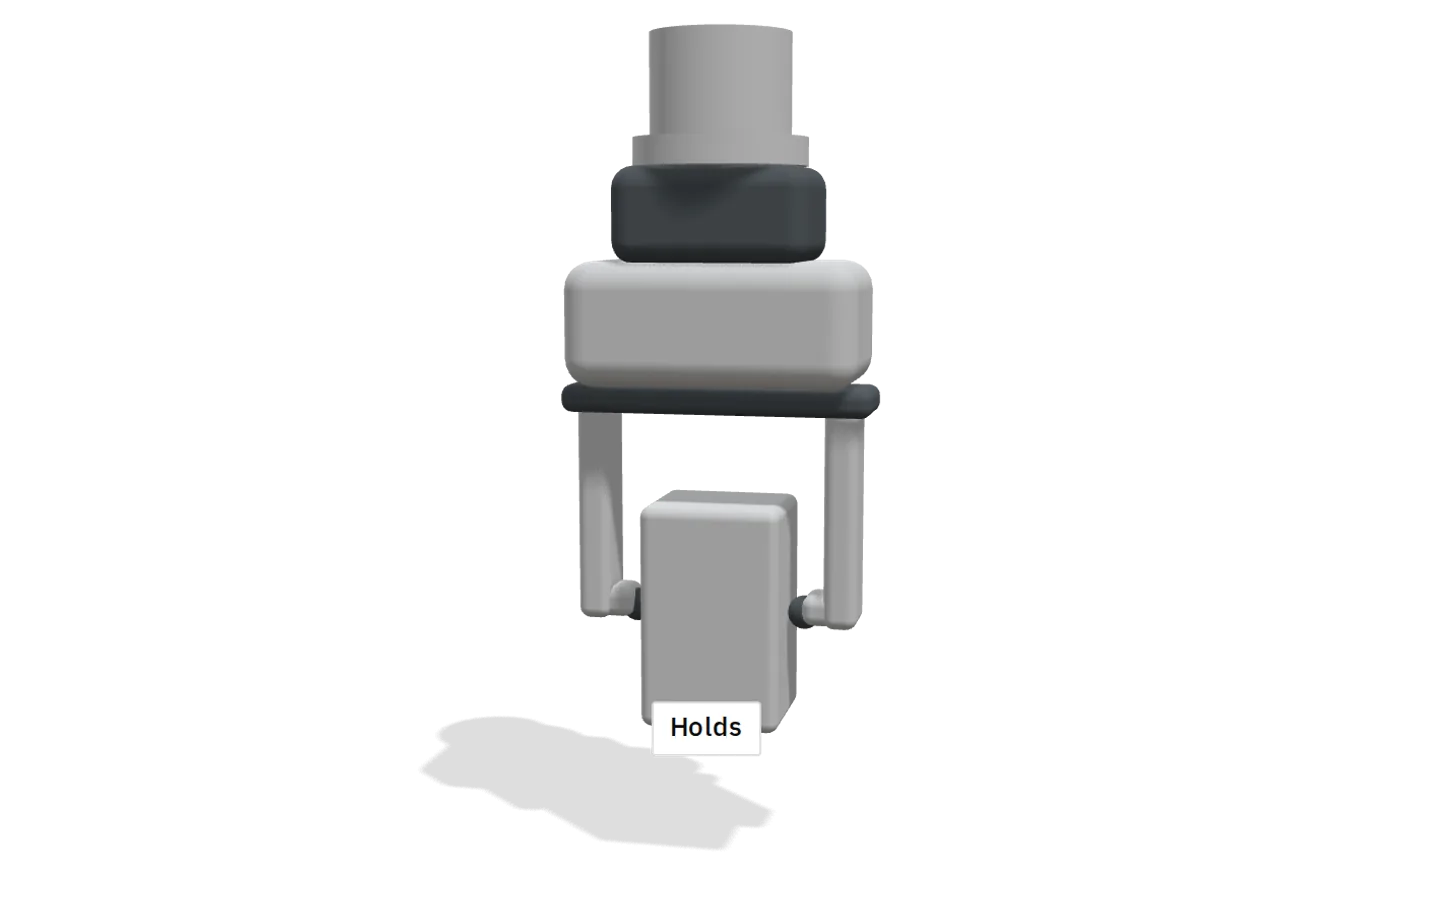
Two fingers pinch a block straight across and lift it. It holds.
A finger can push only at a limited slant before it slides, which is why a tilted grip lets go.
How this was made
The steps in words
- Two fingers pinch a block straight across and lift it. It holds.
- A fingertip can push straight in or at a slant. Any push inside this cone holds; slant further and the finger slides.
- Now it grabs the block with a tilted grip and lifts. The fingers squeeze along the line between them.
- A slippery block narrows the cones. At this tilt, rubber holds, while plastic and ice slip.
- Robots place their fingers so the squeeze line sits well inside both cones. Each cone is called a friction cone.
Cutkosky's taxonomy separates power grasps, which wrap the object for stability, from precision grasps, which hold it in the fingertips for dexteritySource 4. GraspQP reports that simplified force-closure analysis favors power graspsSource 11.
The grasp wrench space
Perception supplies the object pose. A contact force both pushes and twists the object, so its wrench stacks the force over its moment about the object's reference frameSource 1:
In the plane this is with Source 1. The primitive wrenches lie along the cone edges at unit normal force. If each contact's force is limited separately, the grasp wrench space is the convex hull of the Minkowski sum of the contacts' primitive wrenchesSource 8. If the total force is limited, it is the convex hull of their unionSource 8:
Testing whether the origin lies inside this polytope is a ray-shooting problem dual to a linear programSource 12.
Force closure
A grasp has force closure when the contacts can resist any external wrench, so the object's motion is fully constrainedSource 2. That holds exactly when the hull contains a neighborhood of the originSource 1:
An origin on the boundary leaves a disturbance the grasp cannot resist. Uncertainty in friction and contact position can be disastrous for closureSource 13.
Without friction the cone collapses to the normal ray, and form closure, closure by geometry alone, needs at least four wrenches in the plane and seven in space, as Reuleaux noted in 1875 and Somoff in 1897Source 3. Markenscoff, Ni and Papadimitriou showed that four fingers suffice for any planar object with a piecewise smooth boundary except a circle, twelve for any spatial object without rotational symmetry, and seven under very general conditionsSource 3.
With Coulomb friction, three fingers are necessary and sufficient to grasp any planar object, and four in space, under the most relaxed assumptions; a particular object can need fewerSource 3 Source 1. Nguyen's antipodal grasp theorem settles the two-finger planar case: such a grasp with friction is force closure if and only if the line between the contacts lies inside both friction conesSource 2. A differentiable estimator later made force closure an optimization objective that tests closure within milliseconds for arbitrary handsSource 14.
Grasp quality: the epsilon metric
Ferrari and Canny turned the binary test into a number: the quality is the radius of the largest origin-centered ball inside the grasp wrench spaceSource 5.
Because the hull is a polytope, is the distance from the origin to its nearest facetSource 8, and with an -edge polyhedral cone it is an approximationSource 15.
With unit normal forces, is the worst-case disturbance the grasp absorbs per unit of contact force, at the nominal friction. In FIRMGrasp's tests, 53% of nominally force-closed grasps lost closure in the adverse friction tailSource 16, and in a shake test the nominal margin ranked a successful grasp above a failed one with probability only 0.53Source 16. In most cases the grasp most robust to pose error is not the one with the highest Source 17. Predicting grasp stability well required a combination of metricsSource 18.
Roa and Suárez review measures based on contact locations and hand configuration and show that the largest-minimum resisted wrench depends on the torque origin and on the force-torque metric. A grasp optimal under a shared total-force limit need not be optimal under per-finger limits, and most of their analysis is quasi-staticSource 8. FRoGGeR's min-weight metric approximates differentiably and synthesizes grasps in a median 0.834 sSource 19.
Reading the hull
The lab draws the object and each contact's friction cone beside the grasp wrench space projected from , turns the origin ring green under force closure and reports . The default tripod of top, right and bottom contacts is force closure at . Without the bottom contact, the top-right pair's connecting line sits 45 degrees from each normal, outside cones of half-angle degrees, so it fails Nguyen's testSource 2. Sliding contact 2 onto the bottom edge makes the pair antipodal and restores closure for any positive friction, and lowering lowers .
Where this meets the learned stack
Dex-Net 2.0 labels synthetic data with analytic metrics: 6.7 million datapoints from 1,500 object models, positive when expected under object-pose, gripper-pose and friction uncertainty exceeds 0.002 and no collision is modeled. Its GQ-CNN takes a grasp-aligned depth crop and the gripper depth, and predicts robustness without regressing Source 9.
The planner samples antipodal parallel-jaw candidates from depth gradients and executes the most robust reachable, collision-free one. It assumes isolated rigid objects on a planar worksurface and one depth camera with known intrinsics. On an ABB YuMi with silicone fingertips and a Primesense Carmine 1.08, a success meant the object stayed held through lifting, transport and shakingSource 9.
On eight 3D-printed adversarial objects, GQ-L-Adv, fine-tuned on synthetic examples of them, succeeded in 93% of 80 trials. A separate CEM-augmented run of 100 trials on 40 novel household objects, including articulated and deformable ones, reported 94% success and 99% precision: 68 of 69 grasps rated above 50% robustness succeeded. The two evaluations cannot be pooled, and missing depth on thin parts and object collisions remained failure modesSource 9.
Dex-Net 4.0 cleared bins of up to 25 novel objects with over 95% reliability at more than 300 mean picks per hourSource 20. DexGraspNet 2.0 holds 427 million graspsSource 21, and GraspGen-X, a diffusion grasp generator trained on procedural grippers and 2 billion grasps, generalized zero-shot to novel real grippersSource 29.
Learned diffusion policies take contacts from data, but dexterous data pipelines still solve contact mechanics: BODex synthesizes over 49 grasps per second on one RTX 3090 GPUSource 22, and DexEvolve's authors note that analytic synthesis rests on simplifying assumptions that yield infeasible grasps, which high-fidelity simulation must filter outSource 23. A 2026 controller enforces the quality margin during execution, keeping a median 94% of it at 0.09 ms per solveSource 24.
Sim-to-real transfer remained hard for dexterous grasping: Get a Grip found most multi-finger methods degrading on hardwareSource 25. DexGraspNet 2.0 transferred zero-shot to real clutter at 90.7% successSource 21, and RobustDexGrasp, trained in simulation, reached 94.6% on 512 real objectsSource 26. DexGraspVLA reports over 90% success in thousands of unseen cluttered scenesSource 27. Adding wrench and tactile feedback to vision raised one policy from 14 to 24 successes in 25 real trialsSource 28.
GENESIS-Handover, from Marco Hutter (ETH Zurich) and colleagues (October 2026), chooses how a robot presents an object by matching generated task-specific grips to the person's live handSource 30. On a legged manipulator, handovers needing no adjustment rose from 6 to 16 of 60 against AFT-HandoverSource 30.
See also
- Major Datasets
The major open robot datasets and what each collected.
- Cross-Embodiment Transfer
How one policy learns from many robot bodies and from humans.
- Generative Simulation
Generated tasks, scenes and assets inside a physics engine.
Linked from
- Perception for Manipulation
How camera images become an object's position and orientation.
References
Richard M. Murray, Zexiang Li, S. Shankar Sastry, CRC Press, 1994.
https://www.cds.caltech.edu/~murray/books/MLS/pdf/mls94-complete.pdf
Van-Duc Nguyen, Int. J. Robotics Research, 1988.
https://doi.org/10.1177/027836498800700301
Xanthippi Markenscoff, Luqun Ni, Christos H. Papadimitriou, Int. J. Robotics Research, 1990.
https://doi.org/10.1177/027836499000900102
Mark R. Cutkosky, IEEE Trans. Robotics and Automation, 1989.
https://doi.org/10.1109/70.34763
Carlo Ferrari, John F. Canny, ICRA 1992.
https://doi.org/10.1109/ROBOT.1992.219918
Antonio Bicchi, V. Kumar, ICRA 2000.
https://doi.org/10.1109/ROBOT.2000.844081
Domenico Prattichizzo, Jeffrey C. Trinkle, Springer Handbook of Robotics, 2016.
https://doi.org/10.1007/978-3-319-32552-1_38
Máximo A. Roa, Raúl Suárez, Autonomous Robots, 2015.
https://doi.org/10.1007/s10514-014-9402-3
Jeffrey Mahler, Jacky Liang, Sherdil Niyaz, Michael Laskey, Richard Doan, Xinyu Liu, and 2 more, RSS 2017.
https://arxiv.org/abs/1703.09312
J. K. Salisbury, B. Roth, ASME J. Mechanisms, Transmissions, and Automation in Design, 1983.
https://doi.org/10.1115/1.3267342
René Zurbrügg, Andrei Cramariuc, Marco Hutter, 2025.
https://arxiv.org/abs/2508.15002
Yun-Hui Liu, IEEE Trans. Robotics and Automation, 1999.
https://doi.org/10.1109/70.744611
Yu Zheng, Wen-Han Qian, Int. J. Robotics Research, 2005.
https://doi.org/10.1177/0278364905049469
Tengyu Liu, Zeyu Liu, Ziyuan Jiao, Yixin Zhu, Song-Chun Zhu, IEEE Robotics and Automation Letters, 2021.
https://arxiv.org/abs/2104.09194
Florian T. Pokorny, Danica Kragic, IROS 2013.
https://doi.org/10.1109/IROS.2013.6696854
Clinton Enwerem, John S. Baras, Calin Belta, 2026.
https://arxiv.org/abs/2607.25049
Jonathan Weisz, Peter K. Allen, ICRA 2012.
https://doi.org/10.1109/ICRA.2012.6224697
Carlos Rubert, Daniel Kappler, Antonio Morales, Stefan Schaal, Jeannette Bohg, IROS 2017.
https://doi.org/10.1109/IROS.2017.8202167
Albert H. Li, Preston Culbertson, Joel W. Burdick, Aaron D. Ames, IROS 2023.
https://arxiv.org/abs/2302.13687
Jeffrey Mahler, Matthew Matl, Vishal Satish, Michael Danielczuk, Bill DeRose, Stephen McKinley, and 1 more, Science Robotics, 2019.
https://doi.org/10.1126/scirobotics.aau4984
Jialiang Zhang, Haoran Liu, Danshi Li, Xinqiang Yu, Haoran Geng, Yufei Ding, and 2 more, CoRL 2024.
https://arxiv.org/abs/2410.23004
Jiayi Chen, Yubin Ke, He Wang, ICRA 2025, 2024.
https://arxiv.org/abs/2412.16490
René Zurbrügg, Andrei Cramariuc, Marco Hutter, 2026.
https://arxiv.org/abs/2602.15201
Clinton Enwerem, John S. Baras, Calin Belta, 2026.
https://arxiv.org/abs/2608.00600
Tyler Ga Wei Lum, Albert H. Li, Preston Culbertson, Krishnan Srinivasan, Aaron D. Ames, Mac Schwager, and 1 more, 2024.
https://arxiv.org/abs/2410.23701
Hui Zhang, Zijian Wu, Linyi Huang, Sammy Christen, Jie Song, CoRL 2025.
https://arxiv.org/abs/2504.05287
Yifan Zhong, Xuchuan Huang, Ruochong Li, Ceyao Zhang, Zhang Chen, Tianrui Guan, and 6 more, 2025.
https://arxiv.org/abs/2502.20900
Hao Jiang, Luis Dominguez, Daniel Seita, 2026.
https://arxiv.org/abs/2609.24068
Beining Han, Yu-Wei Chao, Erwin Coumans, Clemens Eppner, Balakumar Sundaralingam, Jia Deng, and 2 more, 2026.
https://arxiv.org/abs/2606.00998
Carmen Scheidemann, Andreea Tulbure, Pascal Burkhardt, Marco Hutter, 2026.
https://arxiv.org/abs/2610.08003
Further reading
Bhubaneswar Mishra, Jacob T. Schwartz, Micha Sharir, Algorithmica, 1987.
https://doi.org/10.1007/BF01840373
Li Han, J. C. Trinkle, Z. X. Li, IEEE Trans. Robotics and Automation, 2000.
https://doi.org/10.1109/70.897778
Imin Kao, Kevin M. Lynch, Joel W. Burdick, Springer Handbook of Robotics (2nd ed.), 2016.
https://doi.org/10.1007/978-3-319-32552-1_37
Jiayi Chen, Yubin Ke, Lin Peng, He Wang, RSS 2025.
https://arxiv.org/abs/2504.18829
Jiayi Chen, Yuxing Chen, Jialiang Zhang, He Wang, 2023.
https://arxiv.org/abs/2309.13586
David Kirkpatrick, Bhubaneswar Mishra, Chee-Keng Yap, Discrete & Computational Geometry, 1992.
https://doi.org/10.1007/BF02187843
Z. Li, S. S. Sastry, IEEE J. Robotics and Automation, 1988.
https://doi.org/10.1109/56.769
Ch. Borst, M. Fischer, G. Hirzinger, ICRA 2004.
https://doi.org/10.1109/ROBOT.2004.1307170
Hao-Shu Fang, Chenxi Wang, Minghao Gou, Cewu Lu, CVPR 2020.
https://doi.org/10.1109/CVPR42600.2020.01146
Adithyavairavan Murali, Balakumar Sundaralingam, Yu-Wei Chao, Wentao Yuan, Jun Yamada, Mark Carlson, and 4 more, 2025.
https://arxiv.org/abs/2507.13097
Shengliang Deng, Mi Yan, Songlin Wei, Haixin Ma, Yuxin Yang, Jiayi Chen, and 7 more, 2025.
https://arxiv.org/abs/2505.03233
Spot a factual error or missing qualification? Report a content correction.