Drones and Aerial Robotics
Autonomous flight, from state estimation to champion-level racing.
Aerial robotics is the design and control of robots that fly, from delivery drones and racing quadrotors to swarms. Flight was an early learning success because its dynamics simulate well: a reinforcement-learning system beat human world champions in its own lab in 2023Source 2, and a one-camera drone won an organiser-run race in 2025Source 9.
Switch the drone below between an ordinary camera, which takes about 70 ms to report what it sees, and a faster event camera, and try each swerve setting: the top safe speed moves with every choiceSource 4.
Drone obstacle avoidance
A drone that sees faster can safely fly faster
Camera
How hard it can swerve
At about 69 kilometres an hour the drone flies about 1.3 metres before its camera reports the wall, then swerves for about 6.7 metres.
Adjust more
Lit: flown before the camera reportsDashed: swerveOrdinary camera · standard swerve · top safe speed about 69 km/h
Model from the study; the rig is illustrative
How this was made
Model, from Falanga, Kim and Scaramuzza: maximum speed = range / (latency + 2 sqrt(r / u)), where the range is the 8 m the camera can see, r = 0.75 m is how far the drone must move sideways to clear the obstacle, and u is how hard it can accelerate sideways. The fastest safe speed is the one at which the swerve ends exactly at the wall, so no margin is left after the swerve.
The rig is illustrative. The gauge board in front is to scale along the corridor: the lit rider is the stretch flown before the camera reports (speed times delay), the plain one the swerve. The drone and its sideways throw are drawn larger than that scale. A run plays 10 times slower than the real flight; the carriage starts 1.1 m before the gate, and the timer wheel on it runs down the camera’s delay before the spring pack throws the drone sideways.
Swerve settings, as sideways acceleration: Gentle 10 m/s² (about 1.0 g), Standard, the study’s value, 25 m/s² (about 2.5 g), Hard 50 m/s² (about 5.1 g), Extreme 200 m/s² (about 20.4 g).
Reference latencies from the study (8 m sensing range): Stereo frame camera 70 ms; Event camera 12 ms. “Ordinary camera” is the stereo frame camera and “Faster camera” is the event camera; the camera-delay slider under “Adjust more” sets any latency from 0 to 200 ms.
The same budget on a time axis, at the current settings (Standard (the study’s) swerve):
- Lost to latency, before control acts: 70 ms
- Avoidance maneuver: 346 ms
- Time to contact: 416 ms
- Maximum speed: 19.21 m/s
At 70 ms of perception latency and 25 m/s² lateral agility the sense-and-avoid timeline supports a maximum speed of 19.21 m/s: 70 ms is lost before control acts, 346 ms is the avoidance maneuver, and the swerve ends at the wall at 416 ms time to contact, with no margin left.
Current sense-and-avoid budget
- latency
- 70 ms
- agility
- 25 m/s²
- max speed
- 19.21 m/s
- time to contact
- 416 ms
- avoidance
- 346 ms
Model and reference latencies from Falanga, Kim and Scaramuzza (2019).
Camera delay
A slower camera forces the drone to fly slower
Adjust more
flown before the camera reportsswervingback lane and track: quick camera; front: slow camera
beat 4 / 4 Slow camera: top safe speed about 53 km/h, after flying about 2.9 metres before the wall is reported.
illustrative
When a drone’s camera takes longer to report an obstacle, the drone must fly slower to stay safe, even with the same swerving skill.
How this was made
The starting model is Falanga, Kim and Scaramuzza's: an 8 m sensing range, 25 m/s² of sideways agility and the stereo camera's 70 ms latency, which give 19.21 m/s. The slow camera's 200 ms is a delay chosen for this figure; it gives 14.64 m/s. Both drones swerve for the same fixed avoidance duration of about 346 ms, which depends only on the agility and the 0.75 m it must move sideways. The figure above lets you set the delay directly, under "Adjust more".
Quick camera: 70 ms delay, 19.21 m/s, about 1.3 m flown before the report. Slow camera: 200 ms delay, 14.64 m/s, about 2.9 m. Speeds on the dials are the same values in km/h.
The drawing is the flight-test corridor of the figure above, with two lanes: each drone sits on its test carriage at the light gate, where its camera first sees the wall 8 m ahead, with its timer wheel set to the camera's delay. The gauge board in front is to scale along the 8 m, one track per lane; the drones are drawn larger than that scale.
The four steps, in order:
- A drone’s camera spots a wall 8 metres ahead.
- With a quick camera, the drone flies about 1.3 metres before the wall is reported, then swerves in time at about 69 km/h.
- A slower camera takes longer to report the wall, so the drone must fly slower to keep the same swerve.
- When a drone’s camera takes longer to report an obstacle, the drone must fly slower to stay safe, even with the same swerving skill.
Perception delay lowers the safe speed. Beat 1: A drone’s camera spots a wall 8 metres ahead. Beat 2: With a quick camera, the drone flies about 1.3 metres before the wall is reported, then swerves in time at about 69 km/h. Beat 3: A slower camera takes longer to report the wall, so the drone must fly slower to keep the same swerve. Beat 4: When a drone’s camera takes longer to report an obstacle, the drone must fly slower to stay safe, even with the same swerving skill. The starting model is Falanga, Kim and Scaramuzza's: an 8 m sensing range, 25 m/s² of sideways agility and the stereo camera's 70 ms latency, which give 19.21 m/s. The slow camera's 200 ms is a delay chosen for this figure; it gives 14.64 m/s. Both drones swerve for the same fixed avoidance duration of about 346 ms, which depends only on the agility and the 0.75 m it must move sideways. The figure above lets you set the delay directly, under "Adjust more".
Why flight was the first solved testbed
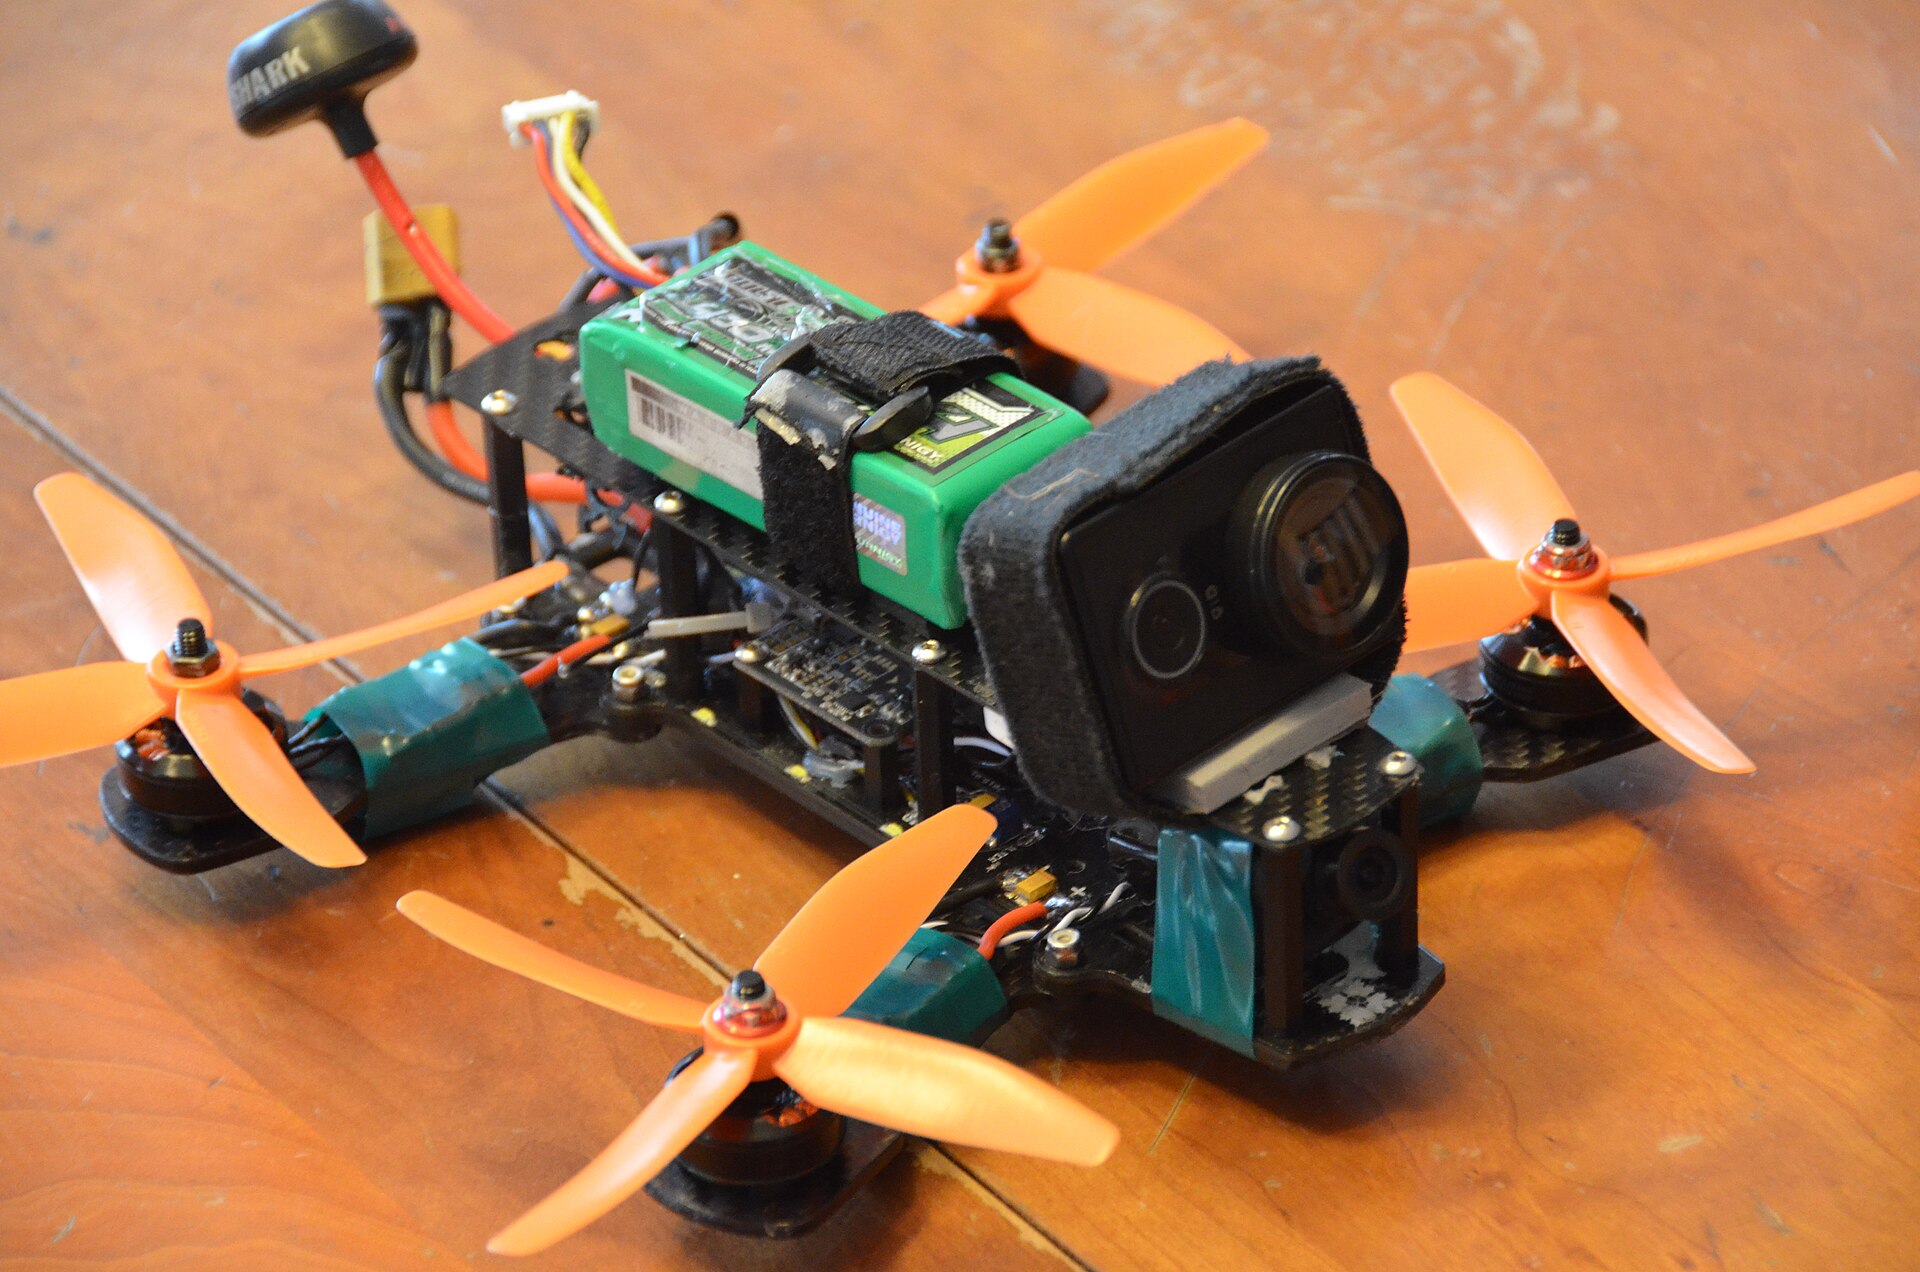
A quadrotor is a benign case for simulation. Its dynamics are differentially flat in position and heading, even with linear rotor dragSource 10, and standard models cover its dynamics, estimation and controlSource 11. Flight also has no contact: an aerial robot either flies in free space or has already failed. Racing quadrotors still exceed 100 km/h and accelerate at several times gravitySource 2. Make the drone in the figure below climb, fly forward and turn, and watch its four propeller speeds change.
How does a drone steer with no wings or rudder?
Loading…
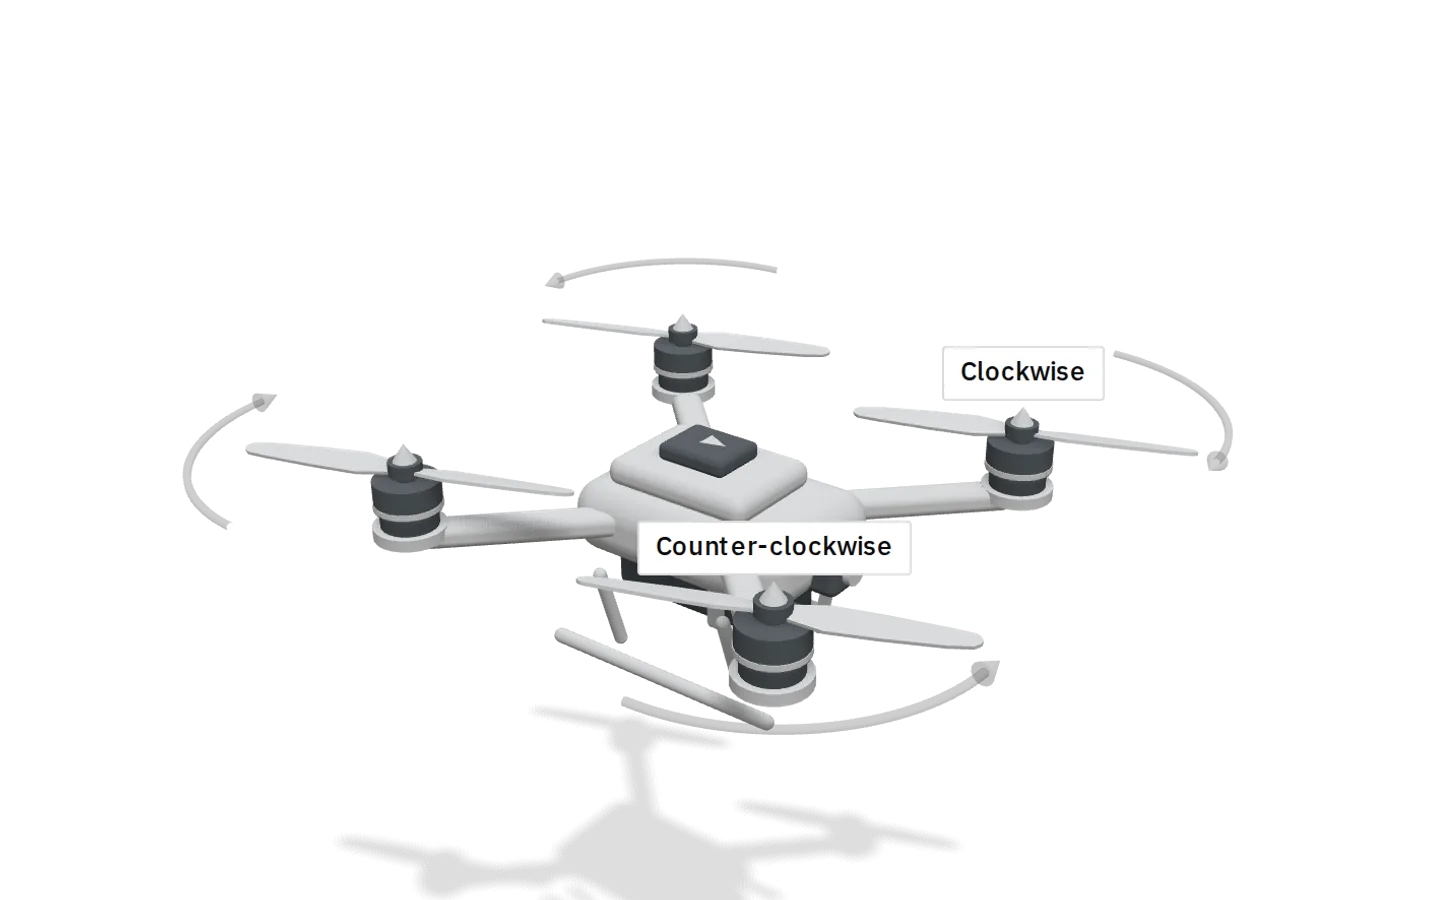
Four motors, a battery and a flight computer. Seen from above, two propellers spin clockwise and two counter-clockwise.
A drone has no wings or rudder, so it moves and turns only by changing how fast each propeller spins.
How this was made
The steps in words
- Four motors, a battery and a flight computer. Seen from above, two propellers spin clockwise and two counter-clockwise.
- Spin all four at the same speed and it hovers: their upward push matches its weight. Faster together, it climbs.
- Now fly forward. No propeller points forward, so something else has to push it that way.
- Each propeller twists the drone against its spin. Speed up the clockwise pair and their twist wins: the drone turns counter-clockwise.
- A gust tips it. The flight computer feels the tilt and resets the four speeds, often 400 times a second. This is attitude control.
Parts
- Frame
- Motors
- Propellers
- Battery
- Flight computer
Classical stacks plan a trajectory and then track it. Mellinger and Kumar generated minimum-snap trajectories for quadrotorsSource 12, and Lee and colleagues built a geometric tracking controller on SE(3)Source 13. In 2021 time-optimal trajectory planning outperformed professional human pilots in racingSource 14.
Swift, from the University of Zurich, raced three human champions, including the world champions of two leagues, and won several races against eachSource 2. It trained its control policy in simulation with model-free reinforcement learningSource 2. The team then fitted residual models of perception noise and unmodeled dynamics from real flight data and retrainedSource 2.
In September 2023, Song and colleagues showed that an RL controller outperformed optimal control on the same racing taskSource 3. Optimal control splits the problem into planning and control with a trajectory as the interface, which limits the controller under unmodeled effects. RL optimizes a task-level objective directly and handles model uncertainty through domain randomization; it flew above 12 g and 108 km/hSource 3. A later hybrid embedded a differentiable MPC in an actor-critic framework and matched model-free RL at up to 21 m/sSource 15.
In April 2025 a TU Delft drone with one rolling-shutter camera and an IMU won the A2RL race in Abu Dhabi, beating all AI teams and three human world champions in a knockout tournamentSource 9. TU Delft notes that Swift raced in a lab where the researchers controlled conditions, hardware and track, while the A2RL organisers designed both hardware and trackSource 16.
In January 2026 world FPV champion Minchan Kim beat TII Racing's drone from a 4 to 4 tie when it struck a gate and could not recoverSource 17. Champion policies stay narrow: they often crash immediately in unseen configurations, and a 2026 method improved generalization 7.4xSource 18.
The autonomy stack on a flying robot
One camera and one low-cost IMU are the minimum sensor suite for metric six-DoF state estimationSource 19. Visual-inertial odometry fuses image features with IMU measurements into the pose and velocity the controller needs, without GPS or motion captureSource 2. The fast inner loop often runs on a microcontroller stack such as PX4, which has substantially lower latency than a typical robotics Linux systemSource 20.
Perception latency bounds the whole system
Falanga, Kim and Scaramuzza asked how fast a drone can fly given its perception latency and the acceleration its airframe can produceSource 4. A drone at speed sees an obstacle at sensing range , and its pipeline delays that information by latency . Avoiding the obstacle at maximum lateral acceleration takes time proportional to the square root of obstacle size over . If is shorter than the maneuver, no controller saves the droneSource 4.
A 70 ms stereo pipeline, the upper bound the study took from a commercial camera's datasheet, supports about 19 m/s at 25 m/s² of lateral acceleration and 25 m/s at 50 m/s²Source 4. An event camera reports per-pixel brightness changes without waiting for a frame. At 8 m of range its ceiling is 7 percent higher on the least agile airframe and 22 percent higher at 50 m/s², 31.03 against 25.40 m/s. The paper's own summary of 7 to 12 percent is for its most agile airframe, at 200 m/s², against the fastest stereo cameraSource 4.
In 2020 an event-camera quadrotor dodged fast-moving objects using only onboard sensing and computationSource 21. Vision-language-action flight is far slower: RaceVLA averaged 1.04 m/s with a top speed of 2.02 m/sSource 22. On the CognitiveDrone benchmark RaceVLA succeeded 31.3 percent of the time, and CognitiveDrone-R1, which adds a reasoning module, 77.2 percentSource 23.
Jaewoo Lee, Guanya Shi and colleagues at Seoul National University, Carnegie Mellon and elsewhere (October 2026) let a coding agent that programs an aerial manipulator run diagnostic programs in simulation, such as a camera move or a test lift, before it declares a task doneSource 37. Over six simulated tasks and 60 trials per condition, the authors report 75 percent success against 31.7 percent with execution logs and final imagesSource 37. Unmodified, the programs completed 4 of 5 real two-object pick-and-place trials and 3 of 5 cabinet trialsSource 37.
End-to-end learning skips the interfaces
Deep Drone Acrobatics trained a policy entirely in simulation by imitating an optimal controller with privileged information, and flew maneuvers at up to 3 gSource 24. In 2021 Loquercio and colleagues used the same recipe to map noisy depth images directly to collision-free trajectoriesSource 1. With realistic simulated sensor noise, the policy transferred to forests, snow, derailed trains and collapsed buildings with no additional training. The authors argue that separating sensing, mapping and planning "can be problematic for high-speed navigation in cluttered environments" because latency compounds and errors propagateSource 1.
Swift kept a modular front end: a visual-inertial estimator and a gate-detection network feed a Kalman filter, and a small two-layer RL network maps that state to collective thrust and body ratesSource 2. Later systems drop explicit state estimation. Geles and colleagues fly from pixels with the thrust and body-rate commands human pilots useSource 25, and Dream to Fly learned racing from pixels with a world model where PPO and SAC struggledSource 26.
MonoRace keeps a state estimator, but its network skips inner-loop controllers and sends motor commands at 500 HzSource 9. Training through differentiable physics produced a depth-to-control policy that flies forests at up to 20 m/s on a $21 computerSource 27.
Swarm robotics
Swarm robotics uses many cheap platforms to cover a search area, map a forest or fly a light show. Its founding models came from biology, Reynolds' 1987 flocking model being the canonical oneSource 8, and treat the group as a dynamical system of local attraction and repulsion. Vásárhelyi and colleagues optimized those terms and flew 30 drones in coherent outdoor flockingSource 7. Reactive models have no lookahead.
| Control family | Mechanism | Demonstrated at | Characteristic limit |
|---|---|---|---|
| Reactive flocking | Potential fields: each drone accelerates away from near neighbors and obstacles, toward the flock | Optimized flocking of 30 drones outdoors (Vásárhelyi et al., 2018) | No lookahead: local minima trap the group, and collision avoidance degrades in clutter |
| Predictive (NMPC) control | Each drone solves a receding-horizon optimization that folds the same interaction terms into its dynamics | Five-quadrotor swarm through an obstacle field (Soria et al., 2021) | Solving an optimization per drone per control step; onboard compute bounds the horizon |
| Decentralized trajectory planning | Each drone replans a full spatial-temporal trajectory in milliseconds, treating neighbors as constraints | Ten palm-sized drones through a bamboo forest (Zhou et al., 2022) | Coordination is implicit: no global assignment, so guarantees are per-trajectory, not fleet-level |
Soria, Schiano and Floreano folded the interaction terms into a nonlinear model-predictive controller with obstacle and neighbour termsSource 6. In simulation it flew faster and with fewer collisions than the reactive equivalent, and five quadrotors flew it through a real indoor obstacle fieldSource 6. EGO-Swarm's agents generate safe, dynamically feasible trajectories in several milliseconds over an unreliable trajectory-sharing networkSource 28.
Zhou and colleagues ran a spatial-temporal trajectory optimizer on palm-sized drones, solving in milliseconds from onboard sensing with no external localizationSource 5. Ten of them flew through a dense bamboo forestSource 5. The differentiable-physics policy coordinates several drones without communication or centralized planningSource 27. Multi-agent RL with league self-play beat a champion-level human pilot in multi-player races above 22 m/s and cut collisions by 50 percent against single-agent baselinesSource 29.
Everything cited above coordinates implicitly; none of it decides who goes where. In Ukraine, electronic warfare is pushing military drones toward terrain-based navigation, autonomous target lock-on and, eventually, mesh-networked swarmsSource 30.
Delivery and regulation
Zipline reports more than 3 million deliveries and more than 140 million commercial autonomous miles since its first commercial delivery in 2016Source 31. In January 2026 it reported US delivery growth of about 15 percent week over week for seven monthsSource 32. Wing reports well over one million commercial deliveries and plans more than 270 Walmart locations reaching 40 million Americans by 2027Source 33. Walmart reported 1 million drone deliveries in May 2026, from 66 stores in four statesSource 34.
The FAA and TSA proposed Part 108 in August 2025 to enable routine flight beyond visual line of sightSource 35. The FAA reopened comments on electronic conspicuity and right-of-way until February 11, 2026Source 36.
What the rest of robotics takes from it
Latency budgets transfer directly. A policy that infers at 20 Hz controls a contact-rich task at about 20 Hz whatever the arm's bandwidth, the reasoning the perception-latency study formalised for flightSource 4. Real-time execution covers that budget for manipulators.
The sim-to-real recipe also carries over: residual models fitted from real dataSource 2 plus privileged imitation with realistic sensor noiseSource 1. Sim-to-real transfer and parallel simulation cover it for other robots.
Champion claims need context. Swift won in its own lab and MonoRace on organiser hardwareSource 16, and the 2026 final turned on one unrecovered gate strikeSource 17. The distance between peak and reliable performance is the reliability gap, and surgical robotics shows a bar cleared under regulatory oversight.
See also
- Real-Time Execution
The latency budgets that decide whether the control loop closes.
- Sim-to-Real Transfer
Domain randomization, distillation, system identification and real-to-sim reconstruction.
- The Reliability Gap
80% task success is a demo; 99.9% is a product.
Linked from
- JEPA and the Non-Generative Counterargument
V-JEPA 2 and 2.1 predict in representation space, with no pixel decoder.
- Autonomous Vehicles
Driving as a robotics problem, down to the long tail.
- Surgical Robotics
From da Vinci to Hugo and OTTAVA, authorized one indication at a time.
- Space Robotics
Robots where repair is impossible, from Mars to orbit.
References
Antonio Loquercio, Elia Kaufmann, René Ranftl, Matthias Müller, Vladlen Koltun, Davide Scaramuzza, Science Robotics 2021, Vol. 6, Issue 59, abg5810.
https://arxiv.org/abs/2110.05113
Elia Kaufmann, Leonard Bauersfeld, Antonio Loquercio, Matthias Müller, Vladlen Koltun, Davide Scaramuzza, Nature 620, 982-987, 2023.
https://www.nature.com/articles/s41586-023-06419-4
Yunlong Song, Angel Romero, Matthias Mueller, Vladlen Koltun, Davide Scaramuzza, Science Robotics 2023, adg1462.
https://arxiv.org/abs/2310.10943
Davide Falanga, Suseong Kim, Davide Scaramuzza, IEEE Robotics and Automation Letters 4(2), 1884-1891, 2019.
https://doi.org/10.1109/LRA.2019.2898117
Xin Zhou, Xiangyong Wen, Zhepei Wang, Yuman Gao, Haojia Li, Qianhao Wang, and 5 more, Science Robotics 7(66), eabm5954, 2022.
https://www.science.org/doi/10.1126/scirobotics.abm5954
Enrica Soria, Fabrizio Schiano, Dario Floreano, Nature Machine Intelligence 3, 545-554, 2021.
https://www.nature.com/articles/s42256-021-00341-y
Gábor Vásárhelyi, Csaba Virágh, Gergő Somorjai, Tamás Nepusz, Agoston E. Eiben, Tamás Vicsek, Science Robotics 3(20), eaat3536, 2018.
https://www.science.org/doi/10.1126/scirobotics.aat3536
Craig W. Reynolds, Computer Graphics 21(4):25-34 (SIGGRAPH '87), 1987.
https://www.red3d.com/cwr/boids/
Stavrow A. Bahnam, Robin Ferede, Till M. Blaha, Anton E. Lang, Erin Lucassen, Quentin Missinne, and 3 more, 2026.
https://arxiv.org/abs/2601.15222
Matthias Faessler, Antonio Franchi, Davide Scaramuzza, IEEE Robotics and Automation Letters 3(2):620-626, 2018.
https://doi.org/10.1109/LRA.2017.2776353
Robert Mahony, Vijay Kumar, Peter Corke, IEEE Robotics & Automation Magazine 19(3):20-32, 2012.
https://doi.org/10.1109/MRA.2012.2206474
Daniel Mellinger, Vijay Kumar, IEEE ICRA 2011, 2520-2525.
https://doi.org/10.1109/ICRA.2011.5980409
Taeyoung Lee, Melvin Leok, N. Harris McClamroch, 49th IEEE Conference on Decision and Control (CDC), 5420-5425, 2010.
https://doi.org/10.1109/CDC.2010.5717652
Philipp Foehn, Angel Romero, Davide Scaramuzza, Science Robotics 6(56):eabh1221, 2021.
https://doi.org/10.1126/scirobotics.abh1221
Angel Romero, Elie Aljalbout, Yunlong Song, Davide Scaramuzza, IEEE Transactions on Robotics 42:673-692, 2026.
https://doi.org/10.1109/TRO.2025.3644945
TU Delft, TU Delft news, 2025-04-15.
https://www.tudelft.nl/en/2025/lr/autonomous-drone-from-tu-delft-defeats-human-champions-in-historic-racing-first
A2RL, A2RL news, 2026-01-23.
https://a2rl.io/news/45/A2RL-Drone-Championship-Sets-the-Pace-for-AI-in-Autonomous-Flight
Jonathan Green, Jiaxu Xing, Nico Messikommer, Angel Romero, Davide Scaramuzza, 2026.
https://arxiv.org/abs/2606.27348
Tong Qin, Peiliang Li, Shaojie Shen, IEEE Transactions on Robotics 34(4):1004-1020, 2018.
https://doi.org/10.1109/TRO.2018.2853729
Lorenz Meier, Dominik Honegger, Marc Pollefeys, IEEE ICRA 2015, 6235-6240.
https://doi.org/10.1109/ICRA.2015.7140074
Davide Falanga, Kevin Kleber, Davide Scaramuzza, Science Robotics 5(40):eaaz9712, 2020.
https://doi.org/10.1126/scirobotics.aaz9712
Valerii Serpiva, Artem Lykov, Artyom Myshlyaev, Muhammad Haris Khan, Ali Alridha Abdulkarim, Oleg Sautenkov, and 1 more, 2025.
https://arxiv.org/abs/2503.02572
Artem Lykov, Valerii Serpiva, Muhammad Haris Khan, Oleg Sautenkov, Artyom Myshlyaev, Grik Tadevosyan, and 2 more, 2025.
https://arxiv.org/abs/2503.01378
Elia Kaufmann, Antonio Loquercio, René Ranftl, Matthias Müller, Vladlen Koltun, Davide Scaramuzza, RSS 2020.
https://arxiv.org/abs/2006.05768
Ismail Geles, Leonard Bauersfeld, Angel Romero, Jiaxu Xing, Davide Scaramuzza, Robotics: Science and Systems XX, 2024.
https://doi.org/10.15607/RSS.2024.XX.082
Angel Romero, Ashwin Shenai, Ismail Geles, Elie Aljalbout, Davide Scaramuzza, ICRA 2026, 2025.
https://arxiv.org/abs/2501.14377
Yuang Zhang, Yu Hu, Yunlong Song, Danping Zou, Weiyao Lin, Nature Machine Intelligence 7(6):954-966, 2025.
https://doi.org/10.1038/s42256-025-01048-0
Xin Zhou, Jiangchao Zhu, Hongyu Zhou, Chao Xu, Fei Gao, ICRA 2021, 2020.
https://arxiv.org/abs/2011.04183
Ismail Geles, Leonard Bauersfeld, Markus Wulfmeier, Davide Scaramuzza, 2026.
https://arxiv.org/abs/2605.22748
Tereza Pultarova, IEEE Spectrum, 2026-03-24.
https://spectrum.ieee.org/autonomous-drone-warfare
Zipline, Zipline, n.d.; accessed 2026-10-14.
https://www.zipline.com/about/zipline-safety-fact-sheet
Team Zipline, Zipline newsroom, 2026-01-21.
https://www.zipline.com/newsroom/zipline-surpasses-2-million-deliveries-raises-more-than-600m-to-power-next-phase-of-growth-and-expands-operations-to-houston-and-phoenix
Wing Team, Wing news, 2026-06-08.
https://wing.com/news/wing-and-walmart-seven-new-markets-drone-delivery
Walmart, Walmart corporate news, 2026-05-29.
https://corporate.walmart.com/news/2026/05/29/walmart-celebrates-1-million-drone-deliveries-marking-a-major-milestone-in-customer-convenience
Federal Aviation Administration, Transportation Security Administration, Federal Register 2025-14992 (NPRM), 2025-08-07.
https://www.federalregister.gov/documents/2025/08/07/2025-14992/normalizing-unmanned-aircraft-systems-beyond-visual-line-of-sight-operations
Federal Aviation Administration, Federal Register 2026-01644, 2026-01-28.
https://www.federalregister.gov/documents/2026/01/28/2026-01644/normalizing-unmanned-aircraft-systems-beyond-visual-line-of-sight-operations-reopening-of-comment
- Fly-by-Code: Embodied Coding Agents for Aerial Manipulation with Active Visual and Physical Feedback
Jaewoo Lee, Jeongyeon Seo, Sihyun Cho, Gyeongrak Choe, Yutong Wang, Bavin Saravanan, and 7 more, 2026.
https://arxiv.org/abs/2610.12549
Spot a factual error or missing qualification? Report a content correction.