Space Robotics
Robots where repair is impossible, from Mars to orbit.
Space robotics is the design and operation of robots beyond Earth, from planetary rovers to station arms and satellite servicers. A signal needs 4 to 20 minutes to reach MarsSource 16, so rovers drive mostly on their ownSource 17, and commercial servicers have docked with satellites in orbit since 2020Source 12.
Autonomy paced by the speed of light
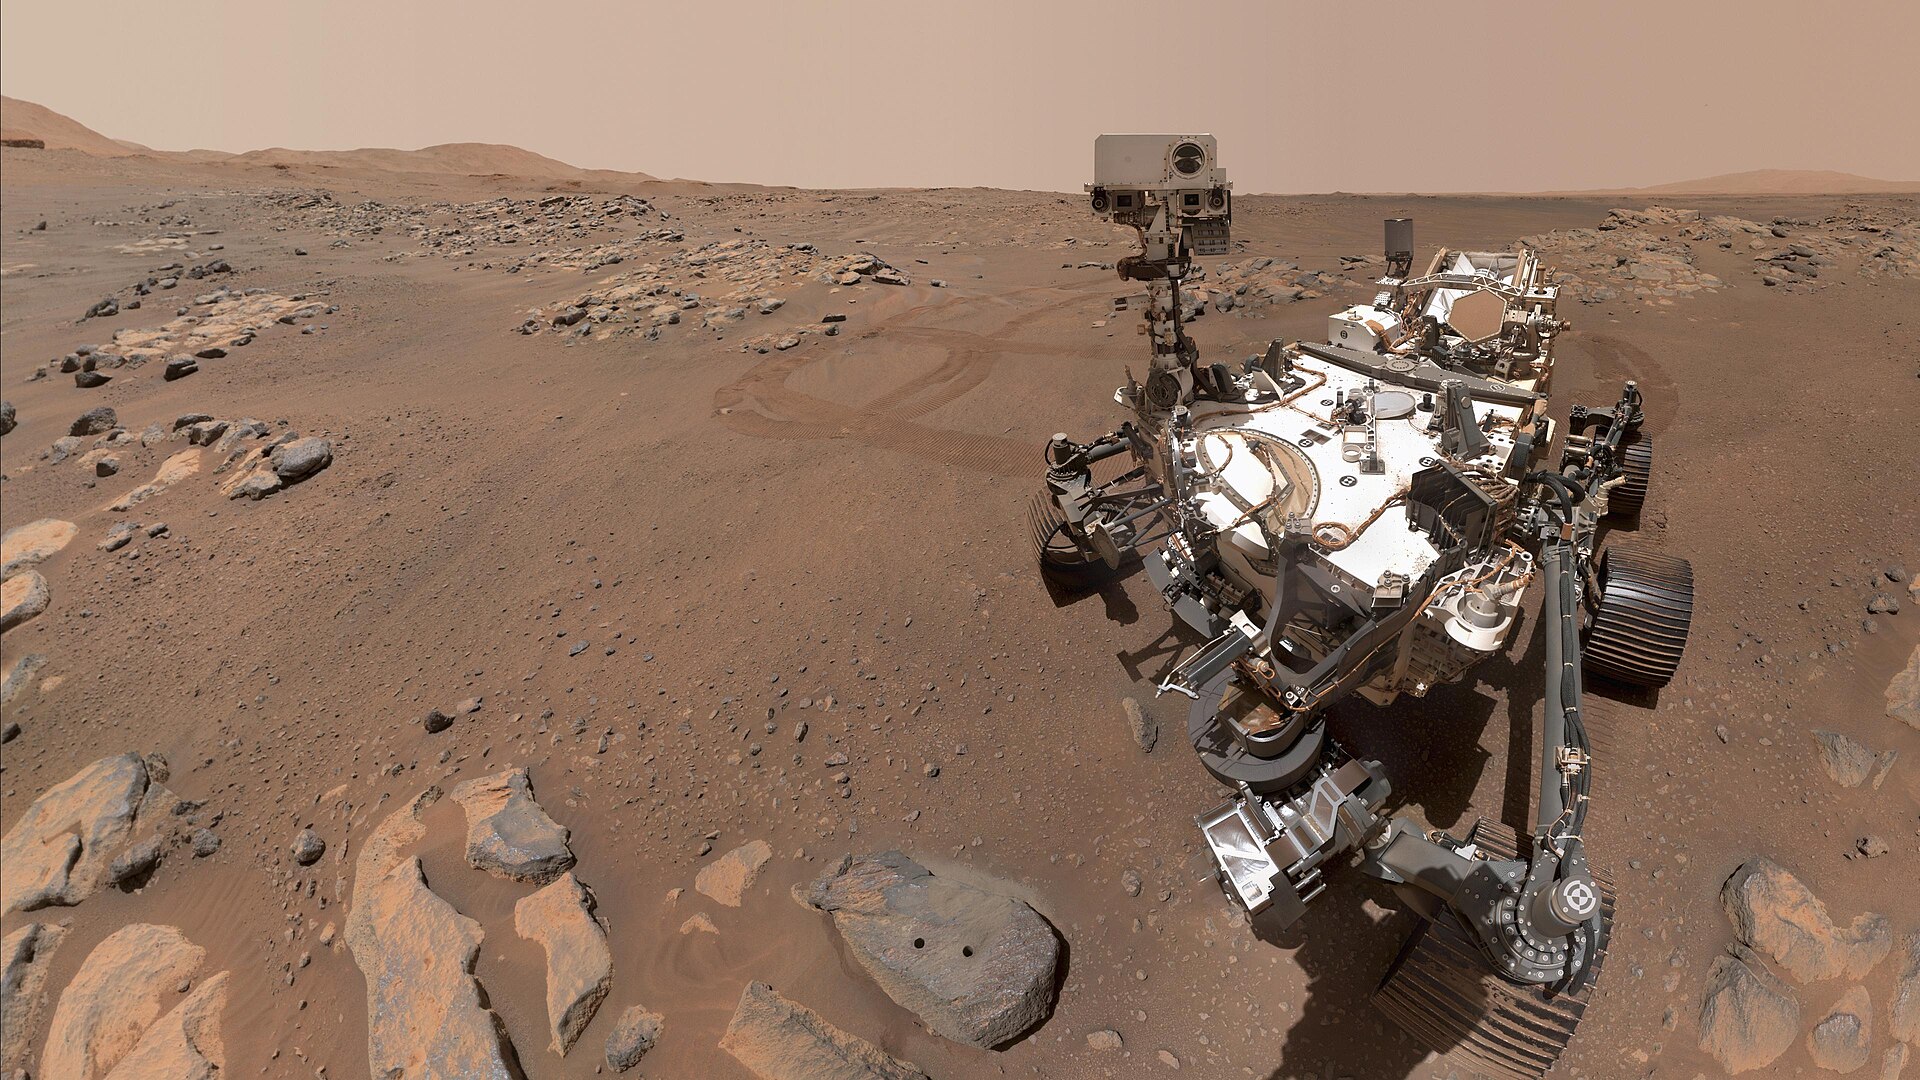
NASA and JPL rovers have used onboard autonomy since 2004Source 18. Sheridan's 1993 review found that space teleoperation had tended to avoid time delay by not teleoperating from the groundSource 19. The Mars Exploration Rovers layered goal-based driving over reactive and predictive safety checks, and drove over 11,000 m combined by October 2005Source 18. They were the first robots to use visual odometry on another world, and within two years it grew from an "extra credit" capability into a critical vehicle safety systemSource 20.
In Perseverance's first Mars year, AutoNav evaluated 88 percent of the 17.7 km driven, against Opportunity's previous record of 2.4 km over fourteen yearsSource 2. It drove 699.9 m without humans reviewing the imagery and 347.7 m in one sol, both planetary rover recordsSource 2. Its Enhanced Autonomous Navigation runs on a single-core CPU and raised average daily driving distance by an order of magnitudeSource 17. By October 28, 2024, it had evaluated the terrain for about 90 percent of 32.1 kmSource 17.
Since February 2026 Perseverance can fix its own position by matching navcam panoramas to orbital imagery, to within 25 cm in about two minutesSource 21. In December 2025 JPL used vision-language models on the ground to generate Perseverance waypoints from HiRISE orbital imagery and terrain-slope dataSource 22. After a digital twin verified over 500,000 telemetry variables, the rover drove 210 m on December 8 and 246 m two days laterSource 22.
Onboard software also picks science targets. On Curiosity since 2016, AEGIS has increased science data return by selecting targets for the ChemCam laser spectrometerSource 1. On Perseverance it picks SuperCam targets from wide-angle images during or right after long drives, without waiting for a ground cycleSource 2. In 2024 NASA described PIXL's "adaptive sampling" as the first use of AI on Mars to make autonomous decisions from real-time rock composition analysisSource 23.
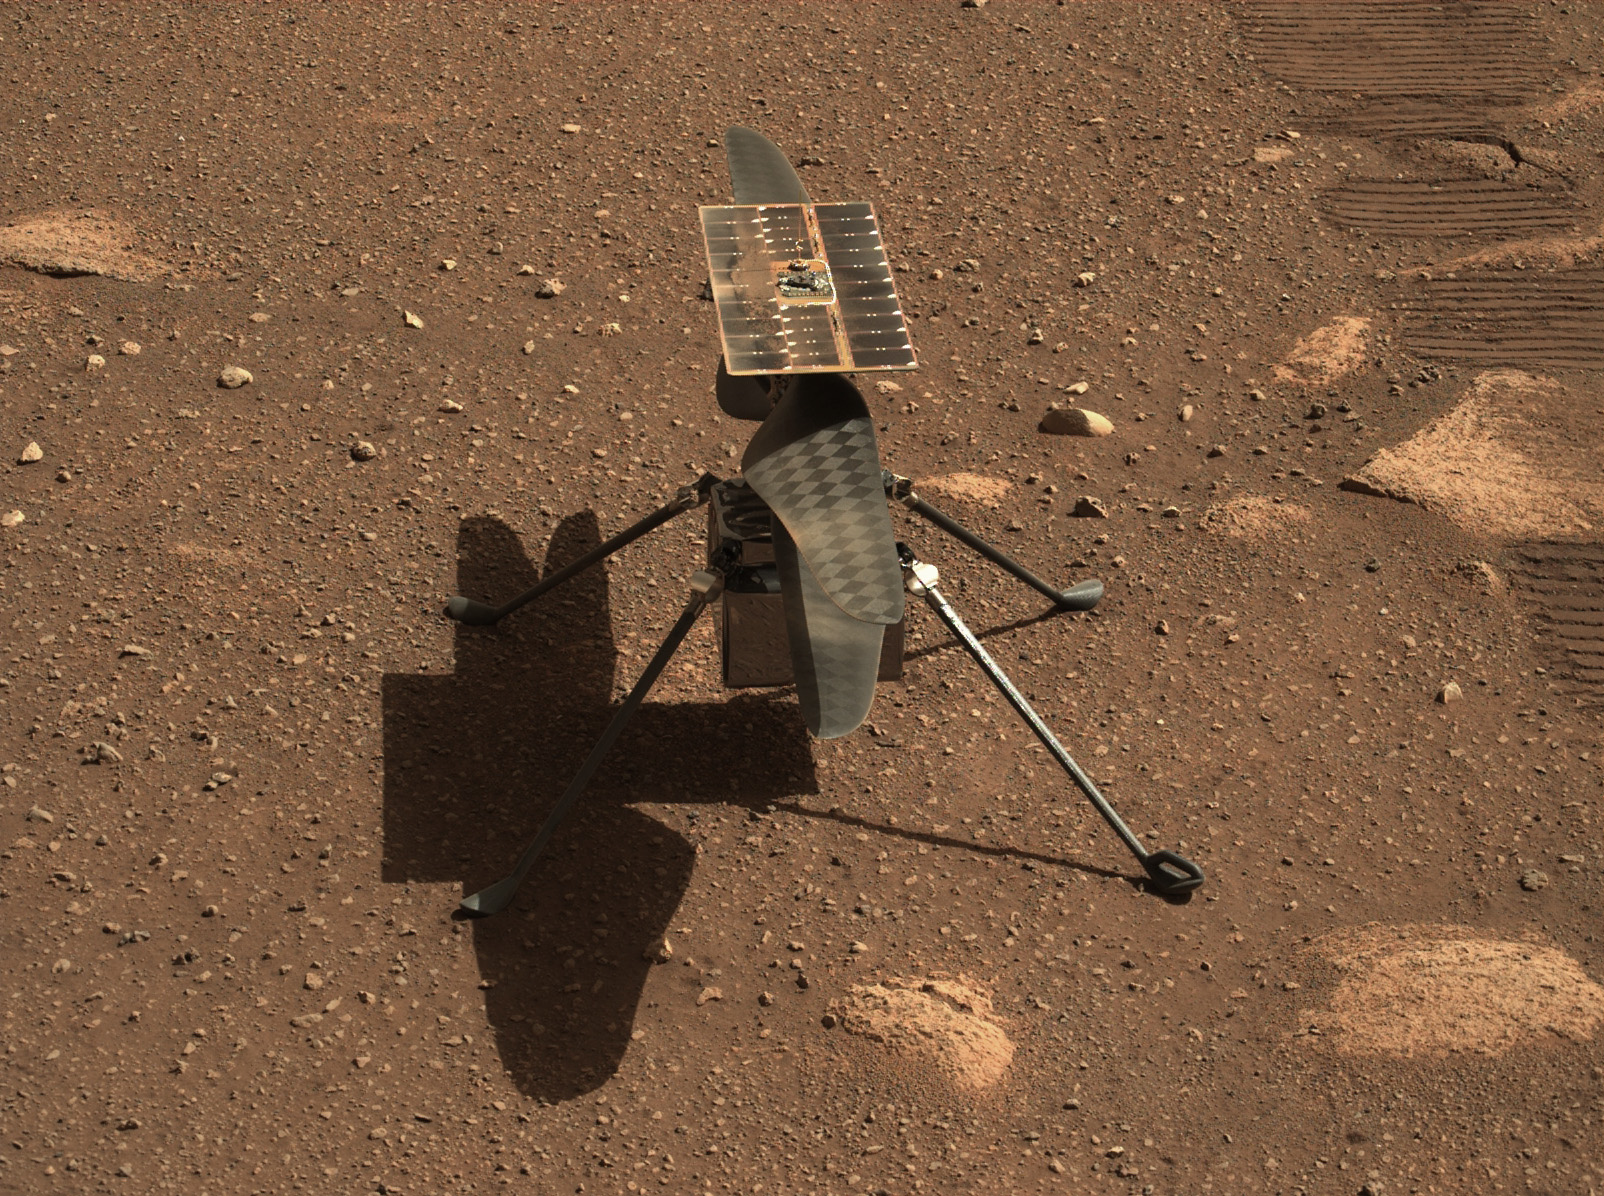
On April 19, 2021, Ingenuity made the first powered, controlled flight on another planet, in an atmosphere with about one percent of Earth's surface pressureSource 4. Designed for five flights over thirty days, it flew 72 times in almost three years before NASA ended the mission in January 2024Source 5. NASA's accident investigation named the most likely cause: a lack of surface texture gave the navigation system too little informationSource 24.
Living off the land: ISRU
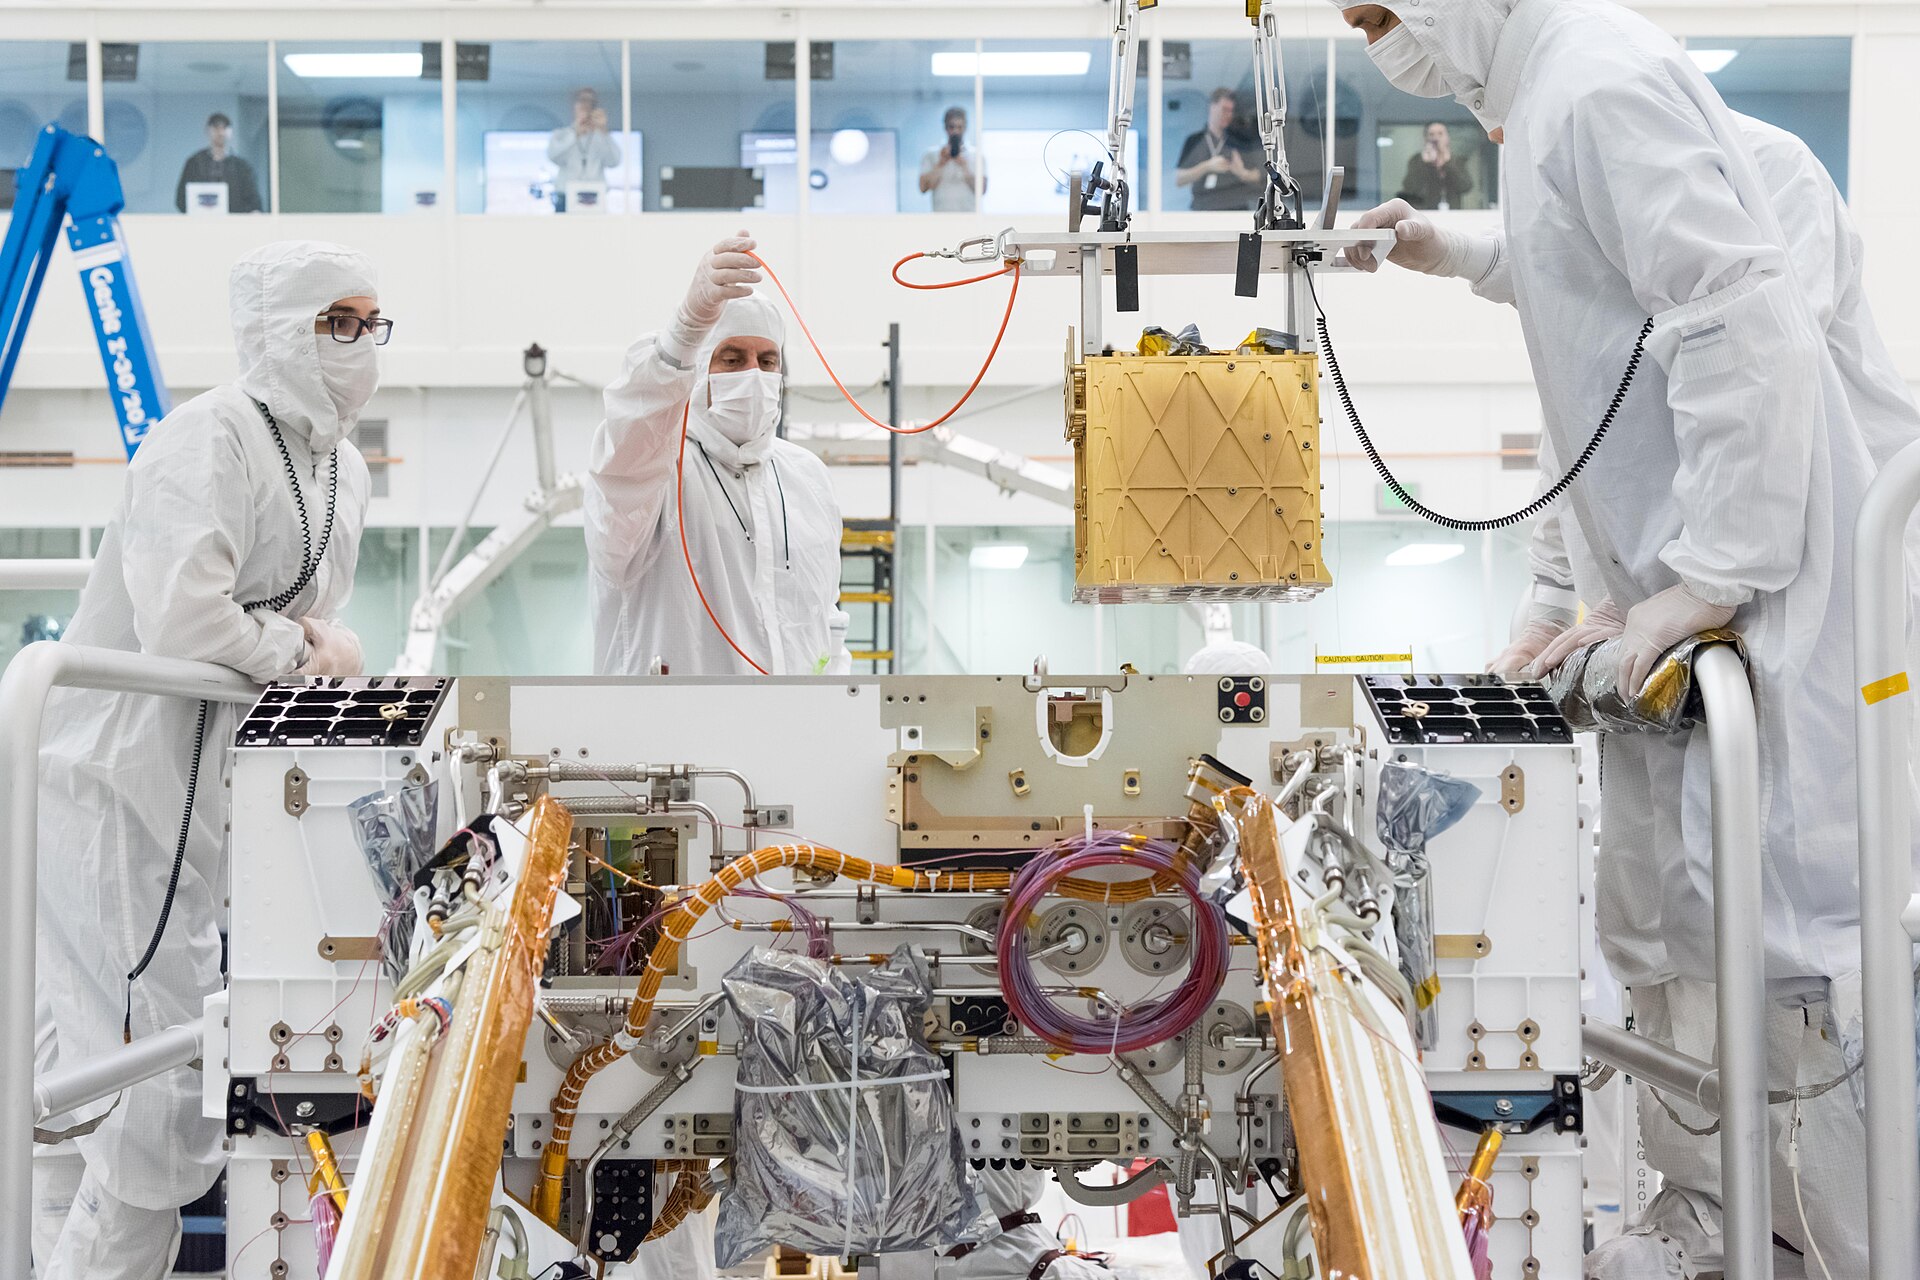
MOXIE, on Perseverance, was the first demonstration of in-situ resource utilization (ISRU) on another planet, making oxygen by solid-oxide electrolysis of atmospheric carbon dioxideSource 25. A scaled-up version would make the tens of tons of oxygen an ascent rocket needs on Mars, instead of launching hundreds of tons from EarthSource 25. Across sixteen runs MOXIE produced 122 grams of oxygen, peaking at 12 grams per hour at 98 percent purity or better, about twice NASA's original goalsSource 3. It concluded operations in September 2023Source 3.
Scaled ISRU means drilling and moving abrasive regolith in vacuum and cold. NASA's PRIME-1 suite reached the lunar south pole on Intuitive Machines' IM-2 lander in March 2025, where the lander, Athena, came to rest on its side in a craterSource 6.
NASA put it about 400 m from its target and the mission at about ten hours of the ten days planned; the PRIME-1 team's 2026 paper gives about 500 m and 12 hoursSource 6 Source 26. TRIDENT, Honeybee Robotics' one-metre rotary-percussive drill, executed its commanded motions, but with the lander on its side it could not reach the surface to excavateSource 6 Source 26. Initial data suggested the MSOLO mass spectrometer detected only gases of human origin, such as propellant and traces of Earth waterSource 6. In evaluation terms PRIME-1 was one trial: the instruments worked while the landing cost the scienceSource 6.
Firefly's Blue Ghost landed on March 2, 2025, four days before Athena, and all its NASA payloads operatedSource 27. Its LISTER probe dug with gas to 1 m, the deepest robotic planetary subsurface thermal probe yetSource 27.
Learned locomotion meets the same regolith in analogue tests on the ground. In October 2026, Adrian Fuhrer, Marco Hutter and colleagues at ETH Zurich reported on a 2025 campaign in the ESA/DLR LUNA lunar analogue facility in Cologne, where the quadrupeds ANYmal-D and Magnecko walked loose regolith simulant and crater-like terrain. The robots could cross the simulant, but sinkage and slip, dust kicked up by foot contacts, and perception failures from overexposure, shadows and low-texture ground all degraded performanceSource 15.
Orbital robotics: servicing and removal
On-orbit servicing covers satellite repair, refuelling, upgrades and debris removalSource 28. It means matching a target's orbit, then docking with it or grasping it. An arm and its base satellite move each other, and in 1989 Umetani and Yoshida derived a generalized Jacobian from momentum conservation to control such armsSource 29. A 2025 review organises capture control around free-floating and free-flying modes, from vision-based estimation to post-capture stabilisationSource 28.
| Mission | Year | Operator | What it demonstrated |
|---|---|---|---|
| ETS-VII (KIKU-7) | 1998 | NASDA (Japan) | Autonomous rendezvous and docking between two satellites, plus a 2-metre, 6-DoF robot arm operated from the ground and in orbit |
| Orbital Express | 2007 | DARPA / Boeing / Ball | Servicer ASTRO autonomously captured the NextSat client and transferred propellant and a battery to it across a four-month flight demonstration |
| Canadarm2 + Dextre | 2001 / 2008 | CSA (on the ISS) | A 17-metre arm that assembled the station and still berths visiting vehicles, working with a two-armed robot that replaces exterior equipment including 100-kg batteries |
| MEV-1 | 2020 | Northrop Grumman | First docking of two commercial spacecraft in orbit, capturing Intelsat 901 in the graveyard orbit and returning it to service for five years |
| ADRAS-J | 2024 | Astroscale (for JAXA) | Rendezvous with a discarded rocket upper stage, fly-around inspections, and a 15-metre approach, the closest any commercial craft has come to debris; controlled deorbit begun by March 25, 2026, after 293 days in orbit |
| Mission Robotic Vehicle | 2026 | Northrop Grumman / DARPA | Launched on July 21, 2026 with the RSGS payload, twin robotic arms built by the U.S. Naval Research Laboratory, to install mission extension pods that extend satellites’ lives |
ROTEX flew on Space Shuttle Columbia in early 1993, worked autonomously, under astronaut teleoperation and under ground control, and grasped free-floating objectsSource 30. Japan's ETS-VII demonstrated autonomous rendezvous and docking between two satellites in 1998, with flight experiments for a 2 m, six-degree-of-freedom armSource 7 Source 8. In DARPA's 2007 Orbital Express, the ASTRO servicer autonomously captured NextSat and transferred propellant and a battery to it over four monthsSource 9 Source 31.
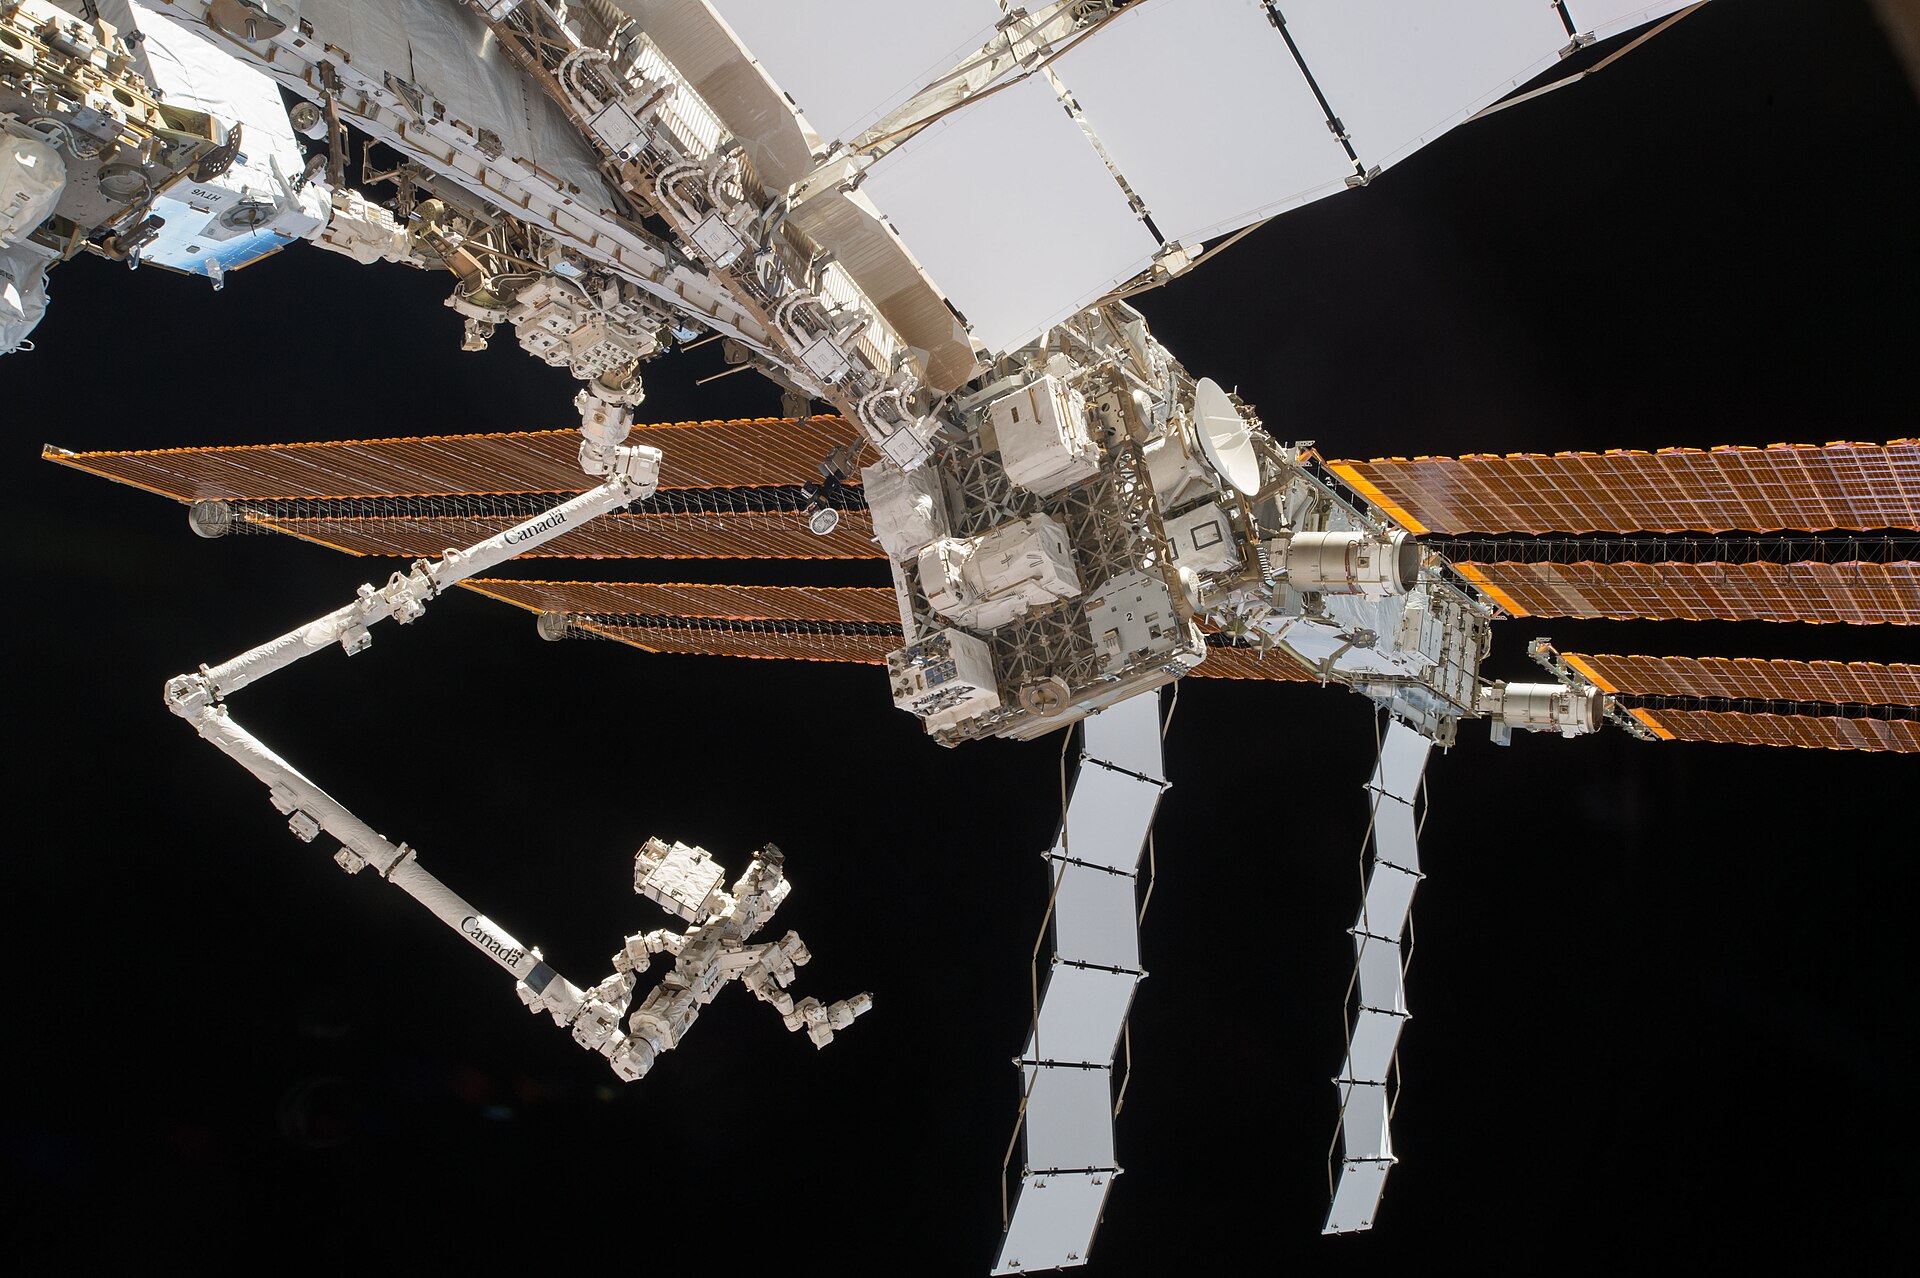
On the International Space Station, Canadarm2, a 17 m arm, assembled the station and still grapples and berths arriving cargo vehiclesSource 10. Dextre, a two-armed robot that rides it, replaces exterior equipment including 100 kg batteries by teleoperation from the groundSource 11.
In 2020 Northrop Grumman's MEV-1 made the first docking of two commercial spacecraft in orbit, capturing Intelsat 901 in the graveyard orbit above geosynchronous altitude and returning it to serviceSource 12. After five years it undocked, the first such undocking in that orbit, and moved to its next missionSource 12. On July 21, 2026, Northrop Grumman's Mission Robotic Vehicle launched with the DARPA-funded RSGS payload, twin robotic arms built by the U.S. Naval Research LaboratorySource 32. It will install small propulsion modules called mission extension pods to extend satellites' livesSource 32.
Debris is the uncooperative case, and ESA's 2026 report states that active debris removal is required to stop collisions multiplying debrisSource 33. In 2024 Astroscale's ADRAS-J, flying for JAXA, inspected a discarded rocket upper stage in three fly-arounds and closed to about 15 mSource 13. No commercial spacecraft had come closer to debris, and the onboard collision-avoidance system aborted autonomously after an unexpected relative attitude anomalySource 13.
By March 25, 2026, ADRAS-J had begun a controlled deorbit after 293 days in orbitSource 34. ADRAS-J2 targets launch in Japan's fiscal year 2027 to capture and remove an upper stage weighing about 3 tSource 35.
NASA discontinued OSAM-1, a mission to refuel an unprepared satellite, in March 2024 after an independent reviewSource 14. It cited technical, cost and schedule challenges and what it called a broader community evolution away from refuelling unprepared spacecraft, which left no committed partnerSource 14. In August 2026 NASA and Katalyst called off the LINK servicer's planned capture and boost of Swift, launched in 2004, over an attitude-control issue on the commercial spacecraftSource 36. NASA expected Swift to re-enter later in 2026Source 36.
What robot learning takes from it
Perception latency of tens of milliseconds caps a drone's safe speedSource 37. Mars delays run to minutes, so spacecraft there must handle off-nominal situations without real-time commanding from EarthSource 16.
Learned control has flown on NASA's Astrobee free-flyers aboard the ISS. In 2025 Banerjee and colleagues reported the first in-space test of learned warm starts for trajectory optimization, while a convex solver still enforced safetySource 38. The network cut solver iterations by 60 percent with rotational dynamics and 50 percent with in-distribution obstaclesSource 38. On May 27, 2025, the Naval Research Laboratory's APIARY team ran what it calls the first reinforcement-learning control of a free-flyer in space, with a policy trained in randomized simulationSource 39.
The Space Robotics Bench authors say costly technology demonstrations and limited data severely hinder robot learning in spaceSource 40. A September 2026 review adds space-specific dynamics and sensing, limited onboard resources and stringent safety requirementsSource 41. AI4MARS offers 326,000 crowdsourced terrain labels on 35,000 rover images, and a model trained on it exceeded 96 percent accuracySource 42.
Space shares its reliability bar with surgical robotics. Ingenuity flew more than fourteen times its five planned flightsSource 5, while OSAM-1 was cancelled before flightSource 14. AEGIS and the digital-twin check on AI-planned drives both add autonomy in bounded, verified stepsSource 1 Source 22.
See also
- Drones and Aerial Robotics
Autonomous flight, from state estimation to champion-level racing.
- State Estimation
Kalman filters, factor graphs, and pose estimation from noisy sensors.
- Vision-Language-Action Models
RT-1, RT-2, Octo and OpenVLA, and what web-scale pretraining adds to robot control.
Linked from
- Surgical Robotics
From da Vinci to Hugo and OTTAVA, authorized one indication at a time.
References
R. Francis, T. Estlin, G. Doran, S. Johnstone, D. Gaines, V. Verma, and 9 more, Science Robotics 2(7), eaan4582, 2017.
https://doi.org/10.1126/scirobotics.aan4582
Vandi Verma, Mark W. Maimone, Daniel M. Gaines, Raymond Francis, Tara A. Estlin, Stephen R. Kuhn, and 6 more, Science Robotics 8(80), adi3099, 2023.
https://doi.org/10.1126/scirobotics.adi3099
NASA Jet Propulsion Laboratory, NASA/JPL news, 6 September 2023.
https://www.jpl.nasa.gov/news/nasas-oxygen-generating-experiment-moxie-completes-mars-mission/
NASA Jet Propulsion Laboratory, NASA/JPL news, 19 April 2021.
https://www.jpl.nasa.gov/news/nasas-ingenuity-mars-helicopter-succeeds-in-historic-first-flight/
NASA, NASA news release, 25 January 2024.
https://www.nasa.gov/news-release/after-three-years-on-mars-nasas-ingenuity-helicopter-mission-ends/
NASA, NASA article, 29 April 2025.
https://www.nasa.gov/missions/artemis/nasas-lunar-drill-technology-passes-tests-on-the-moon/
Isao Kawano, Masaaki Mokuno, Toru Kasai, Takashi Suzuki, Journal of Spacecraft and Rockets 38(1), 105-111, 2001.
https://doi.org/10.2514/2.3661
Kazuya Yoshida, Experimental Robotics VII, Lecture Notes in Control and Information Sciences, 209-218, 2001.
https://doi.org/10.1007/3-540-45118-8_22
Robert B. Friend, Proc. SPIE 6958, Sensors and Systems for Space Applications II, 2008.
https://doi.org/10.1117/12.783792
Canadian Space Agency, Canadian Space Agency, 2024.
https://www.asc-csa.gc.ca/eng/iss/canadarm2/about.asp
Canadian Space Agency, Canadian Space Agency, 2024.
https://www.asc-csa.gc.ca/eng/iss/dextre/about.asp
Northrop Grumman, Northrop Grumman news, 9 April 2025.
https://news.northropgrumman.com/satellites/Northrop-Grumman-Achieves-First-Ever-Undocking-Between-Two-Commercial-Spacecraft-in-Geosynchronous-Orbit
Astroscale Japan, Astroscale announcement, 11 December 2024.
https://www.astroscale.com/en/news/astroscales-adras-j-achieves-historic-15-meter-approach-to-space-debris
NASA, NASA, 1 March 2024.
https://www.nasa.gov/missions/update-on-status-of-nasas-osam-1-project/
Adrian Fuhrer, Joseph Church, Oliver Fischer, William Talbot, Nicolas Faesch, Yannic Hofmann, and 3 more, 2026.
https://arxiv.org/abs/2610.12276
Yoaz Bar-Sever, Eric Burt, Kar-Ming Cheung, Todd Ely, Jon Hamkins, Stephen M. Lichten, and 5 more, IPN Progress Report 42-237, 15 May 2024.
https://ipnpr.jpl.nasa.gov/progress_report/42-237/42-237A.pdf
J. J. Biesiadecki, M. W. Maimone, 2006 IEEE Aerospace Conference, 1-15.
https://doi.org/10.1109/AERO.2006.1655723
T. B. Sheridan, IEEE Transactions on Robotics and Automation 9(5):592-606, 1993.
https://doi.org/10.1109/70.258052
Mark Maimone, Yang Cheng, Larry Matthies, Journal of Field Robotics 24(3):169-186, 2007.
https://doi.org/10.1002/rob.20184
NASA Jet Propulsion Laboratory, NASA Photojournal PIA26705, 18 February 2026.
https://science.nasa.gov/photojournal/mars-global-localization-pinpoints-perseverances-location/
NASA Jet Propulsion Laboratory, NASA/JPL news, 30 January 2026.
https://www.nasa.gov/missions/mars-2020-perseverance/perseverance-rover/nasas-perseverance-rover-completes-first-ai-planned-drive-on-mars/
NASA Jet Propulsion Laboratory, NASA/JPL news, 16 July 2024.
https://www.nasa.gov/missions/mars-2020-perseverance/perseverance-rover/heres-how-ai-is-changing-nasas-mars-rover-science/
NASA Jet Propulsion Laboratory, NASA/JPL news, 11 December 2024.
https://www.nasa.gov/missions/mars-2020-perseverance/ingenuity-helicopter/nasa-performs-first-aircraft-accident-investigation-on-another-world/
Jeffrey A. Hoffman, Michael H. Hecht, Donald Rapp, Joseph J. Hartvigsen, Jason G. SooHoo, Asad M. Aboobaker, and 18 more, Science Advances 8(35):eabp8636, 2022.
https://doi.org/10.1126/sciadv.abp8636
Matthew Hancock, Roberto Aguilar Ayala, Julie Kleinhenz, James Smith, Prital Johnson, Rolando Nieves, and 24 more, The Planetary Science Journal 7(7):159, 2026.
https://doi.org/10.3847/PSJ/ae732f
NASA, NASA missions blog, 14 March 2025.
https://www.nasa.gov/blogs/missions/2025/03/14/nasa-science-data-received-blue-ghost-captures-eclipse-from-moon/
Nasim Fallahiarezoodar, Zheng H. Zhu, Space: Science & Technology 5:0291, 2025.
https://doi.org/10.34133/space.0291
Y. Umetani, K. Yoshida, IEEE Transactions on Robotics and Automation 5(3):303-314, 1989.
https://doi.org/10.1109/70.34766
G. Hirzinger, B. Brunner, J. Dietrich, J. Heindl, IEEE Transactions on Robotics and Automation 9(5):649-663, 1993.
https://doi.org/10.1109/70.258056
Boeing, Boeing news release, 17 April 2007.
https://boeing.mediaroom.com/2007-04-17-Boeing-Orbital-Express-Conducts-First-Autonomous-Spacecraft-to-Spacecraft-Fluid-and-Component-Transfer
Colleen Wouters, NASA Goddard Space Flight Center, 22 July 2026.
https://www.nasa.gov/technology/robotic-servicing-mission-launches-with-nasa-support/
ESA, European Space Agency, Space Safety, 2026.
https://www.esa.int/Space_Safety/Space_Debris/ESA_Space_Environment_Report_2026
Astroscale Japan, Astroscale mission update, 25 March 2026.
https://www.astroscale.com/en/news/astroscales-adras-j-mission-completes-operations-begins-deorbit
Astroscale Japan, Astroscale mission update, 1 September 2026.
https://www.astroscale.com/en/news/astroscale-japan-selects-isar-aerospace-to-launch-adras-j2
NASA, NASA news release 26-067, 19 August 2026.
https://www.nasa.gov/news-release/nasa-updates-next-steps-for-commercial-swift-boost-mission/
Davide Falanga, Suseong Kim, Davide Scaramuzza, IEEE Robotics and Automation Letters 4(2), 1884-1891, 2019.
https://doi.org/10.1109/LRA.2019.2898117
Somrita Banerjee, Abhishek Cauligi, Marco Pavone, 2025 International Conference on Space Robotics (iSpaRo).
https://arxiv.org/abs/2505.05588
Samantha Chapin, Kenneth Stewart, Roxana Leontie, Carl Glen Henshaw, 2025 International Conference on Space Robotics (iSpaRo).
https://arxiv.org/abs/2512.03729
Andrej Orsula, Matthieu Geist, Miguel Olivares-Mendez, Carol Martinez, 2025.
https://arxiv.org/abs/2509.23328
Zeyuan Huang, Gang Chen, Zixuan Hao, Guoqin Tang, Junyi Zong, Guoyou Ban, and 4 more, 2026.
https://arxiv.org/abs/2609.16880
R. Michael Swan, Deegan Atha, Henry A. Leopold, Matthew Gildner, Stephanie Oij, Cindy Chiu, and 1 more, CVPR Workshops 2021, 1982-1991.
https://openaccess.thecvf.com/content/CVPR2021W/AI4Space/html/Swan_AI4MARS_A_Dataset_for_Terrain-Aware_Autonomous_Driving_on_Mars_CVPRW_2021_paper.html
Spot a factual error or missing qualification? Report a content correction.